articulated technology
A-Bot
Articulated robots, and the control that moves them.
Leveraging our software technologies, we build and control articulated, long-reach robots for the most complex environments.
Integrated Actuators
Compact motors integrated within joints
Long Reach
Extended workspace for remote operations
Multi-Axis Motion
Flexible movement across multiple directions
Modular Architecture
Adaptable configuration for different applications
software in the loop
Custom
Kinematic chain, end-effectors and sensors configured around your task.
in the field
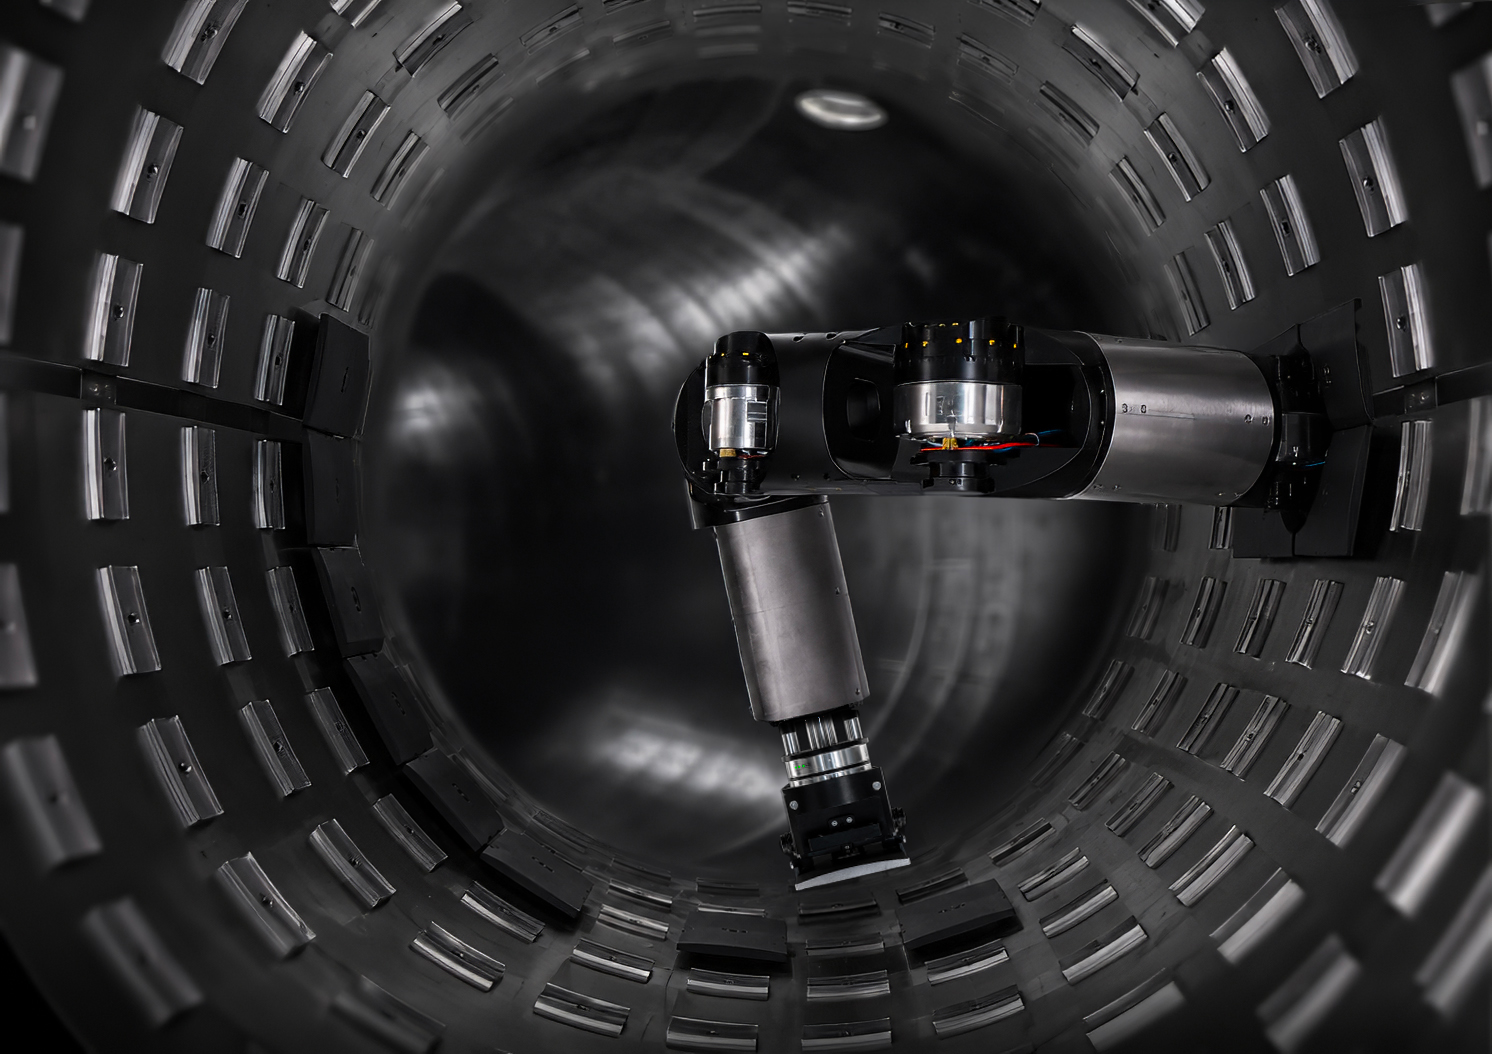
A-BOT was applied to Roman, the long-reach robotic arm built for Consorzio RFX in the NEFERTARI project, and to our flexible-link test-rig, developed within the LongOps programme to validate modelling and vibration-control algorithms on long, highly flexible manipulators before applying them to the robots the programme targeted: TARM at JET and the Fukushima Daiichi system. The test-rig remains an internal asset.
Cheliped Two, the blockage-removal arm in the PIPEON project, is also built on A-BOT.
tendon driven technology
T-Bot
Precision and agility where nothing else fits.
Highly flexible and versatile robotic systems, ranging from continuous to articulated robots, actuated by tendons. Robotic solutions capable to perform industrial tasks such as inspection and manufacturing in confined and constrained spaces with precision and agility.
Dexterous
Thin, slender and a slight manipulator
Lightweight
Tendon driven system at the base link
Custom
Reconfigurable task-oriented kinematics
Multi-Tool
Ability to add many tools and sensors
sensors & tools
sizes
Three tested sizes.
Three different sizes, customizable following your application. The three arm sections below are nested and dimensioned, drawn 1:1 in millimetres.
Custom
Kinematic chain, end-effectors and sensors configured around your task.
patent
Italian patent no. 102024000021885, the joint technology behind T-Bot. International extension through PCT.
in the field
T-BOT works today as a dexterous tool at the tip of a collaborative robot in our bonding cell, where it dispenses adhesive in very tight areas, and as a manipulator for confined spaces such as the inside of pipes: in the European project PIPEON it is the technology behind Cheliped One.
pneumatic growing technology
G-Bot
Long reach through openings nothing else passes.
Continuum pneumatic robots made of a soft body with eversion and retraction capabilities. Robotic solutions capable of delivering sensors and tools in long-reach, constrained locations, with high adaptability to the surrounding environments.
Flexible
Textile soft body for safe interactions
Lightweight
Deployable and pneumatic driven
Adaptive
Suitable for unstructured sites
Bioinspired
Inspired by naturalistic principles
sensors & tools
sizes
Three tested sizes.
Three different sizes, customizable following your application. HRG20 and HRG80 are drawn nested and 1:1 in millimetres below.
Custom
Custom shape, end-effectors and sensors configured around your task.
patent
The method and the results are published in a peer-reviewed journal.
European patent no. EP4360816, Process for designing and manufacturing an everting soft robot.
less body material than the standard build method
stiffer than the standard build method
faster than manual procedure · remote inspection
faster than manual procedure · cable delivery
Partners & clients