What you receive
Nine software modules. Delivered as one system
Each module is configurable and can be deployed independently, according to the robots and the missions of the facility. The dynamic simulation engine predicts the behaviour of a flexible robot, whole-body collision detection covers the full arm, and the control layer uses that prediction to keep the manipulator steady.
Flexible Dynamic Simulation
Dynamic solver for long-reach, rigid and flexible robots in real time.
Collision Detection
Continuous distance computation between the robot and the environment.
Virtual Reality
Immersive validation of procedures with synthetic views and no cameras.
Haptic Teleoperation
Force-feedback control, with active suppression of oscillation on flexible links.
Motion Planning
Optimised trajectories for redundant kinematics in constrained spaces.
Safety and Diagnostics
PLC-based safety chain with continuous monitoring of every subsystem.
Procedure Planning
Structured task sequences prepared, reviewed and replayed before execution.
Data Management
Centralised acquisition, storage and traceability of operational data.
Sensing Integration
Cameras, telemetry, tracking and external equipment unified in one operator view.
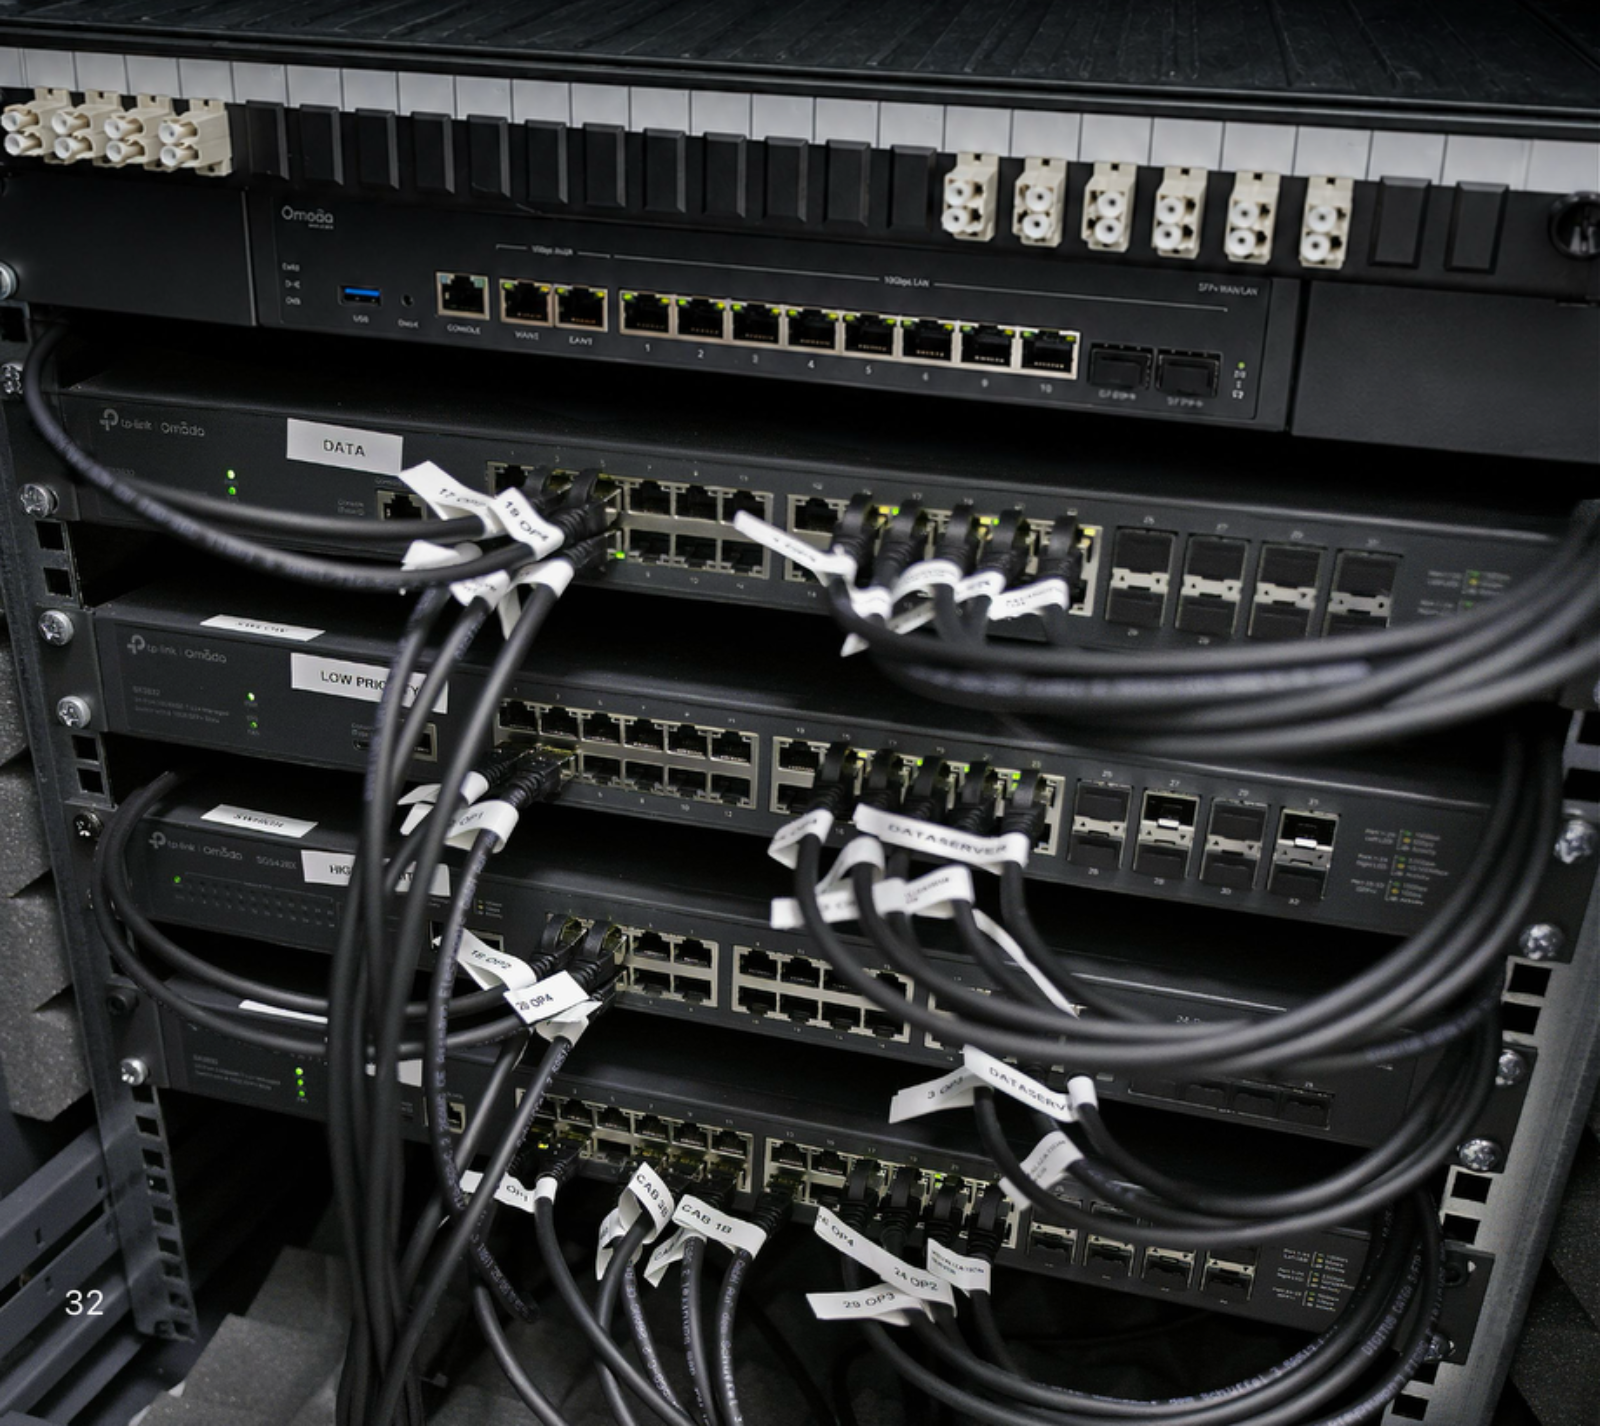
network
System architecture
The Control Room is built on a segmented, deterministic network architecture designed to ensure reliable, secure and low-latency communication between all the hardware and software components. Dedicated subnets, managed industrial Ethernet switches, and static IP addressing isolate critical communication paths, while simplifying maintenance and diagnostics. Data exchange between internal systems is based on the Data Distribution Service (DDS) middleware, providing scalable communication with configurable Quality of Service policies
for fault-tolerant operation under sustained load. High-performance distributed servers host simulation, planning, visualization, data management, and communication services for the whole system, while operator workstations provide access to custom HMI, teleoperation devices, haptic interfaces and immersive VR digital twins in a unified software environment. The network integrates robotic controllers, vision and tracking systems, PLCs, safety devices and auxiliary equipment, enabling coordinated operation with multiple robots and operators.
01.
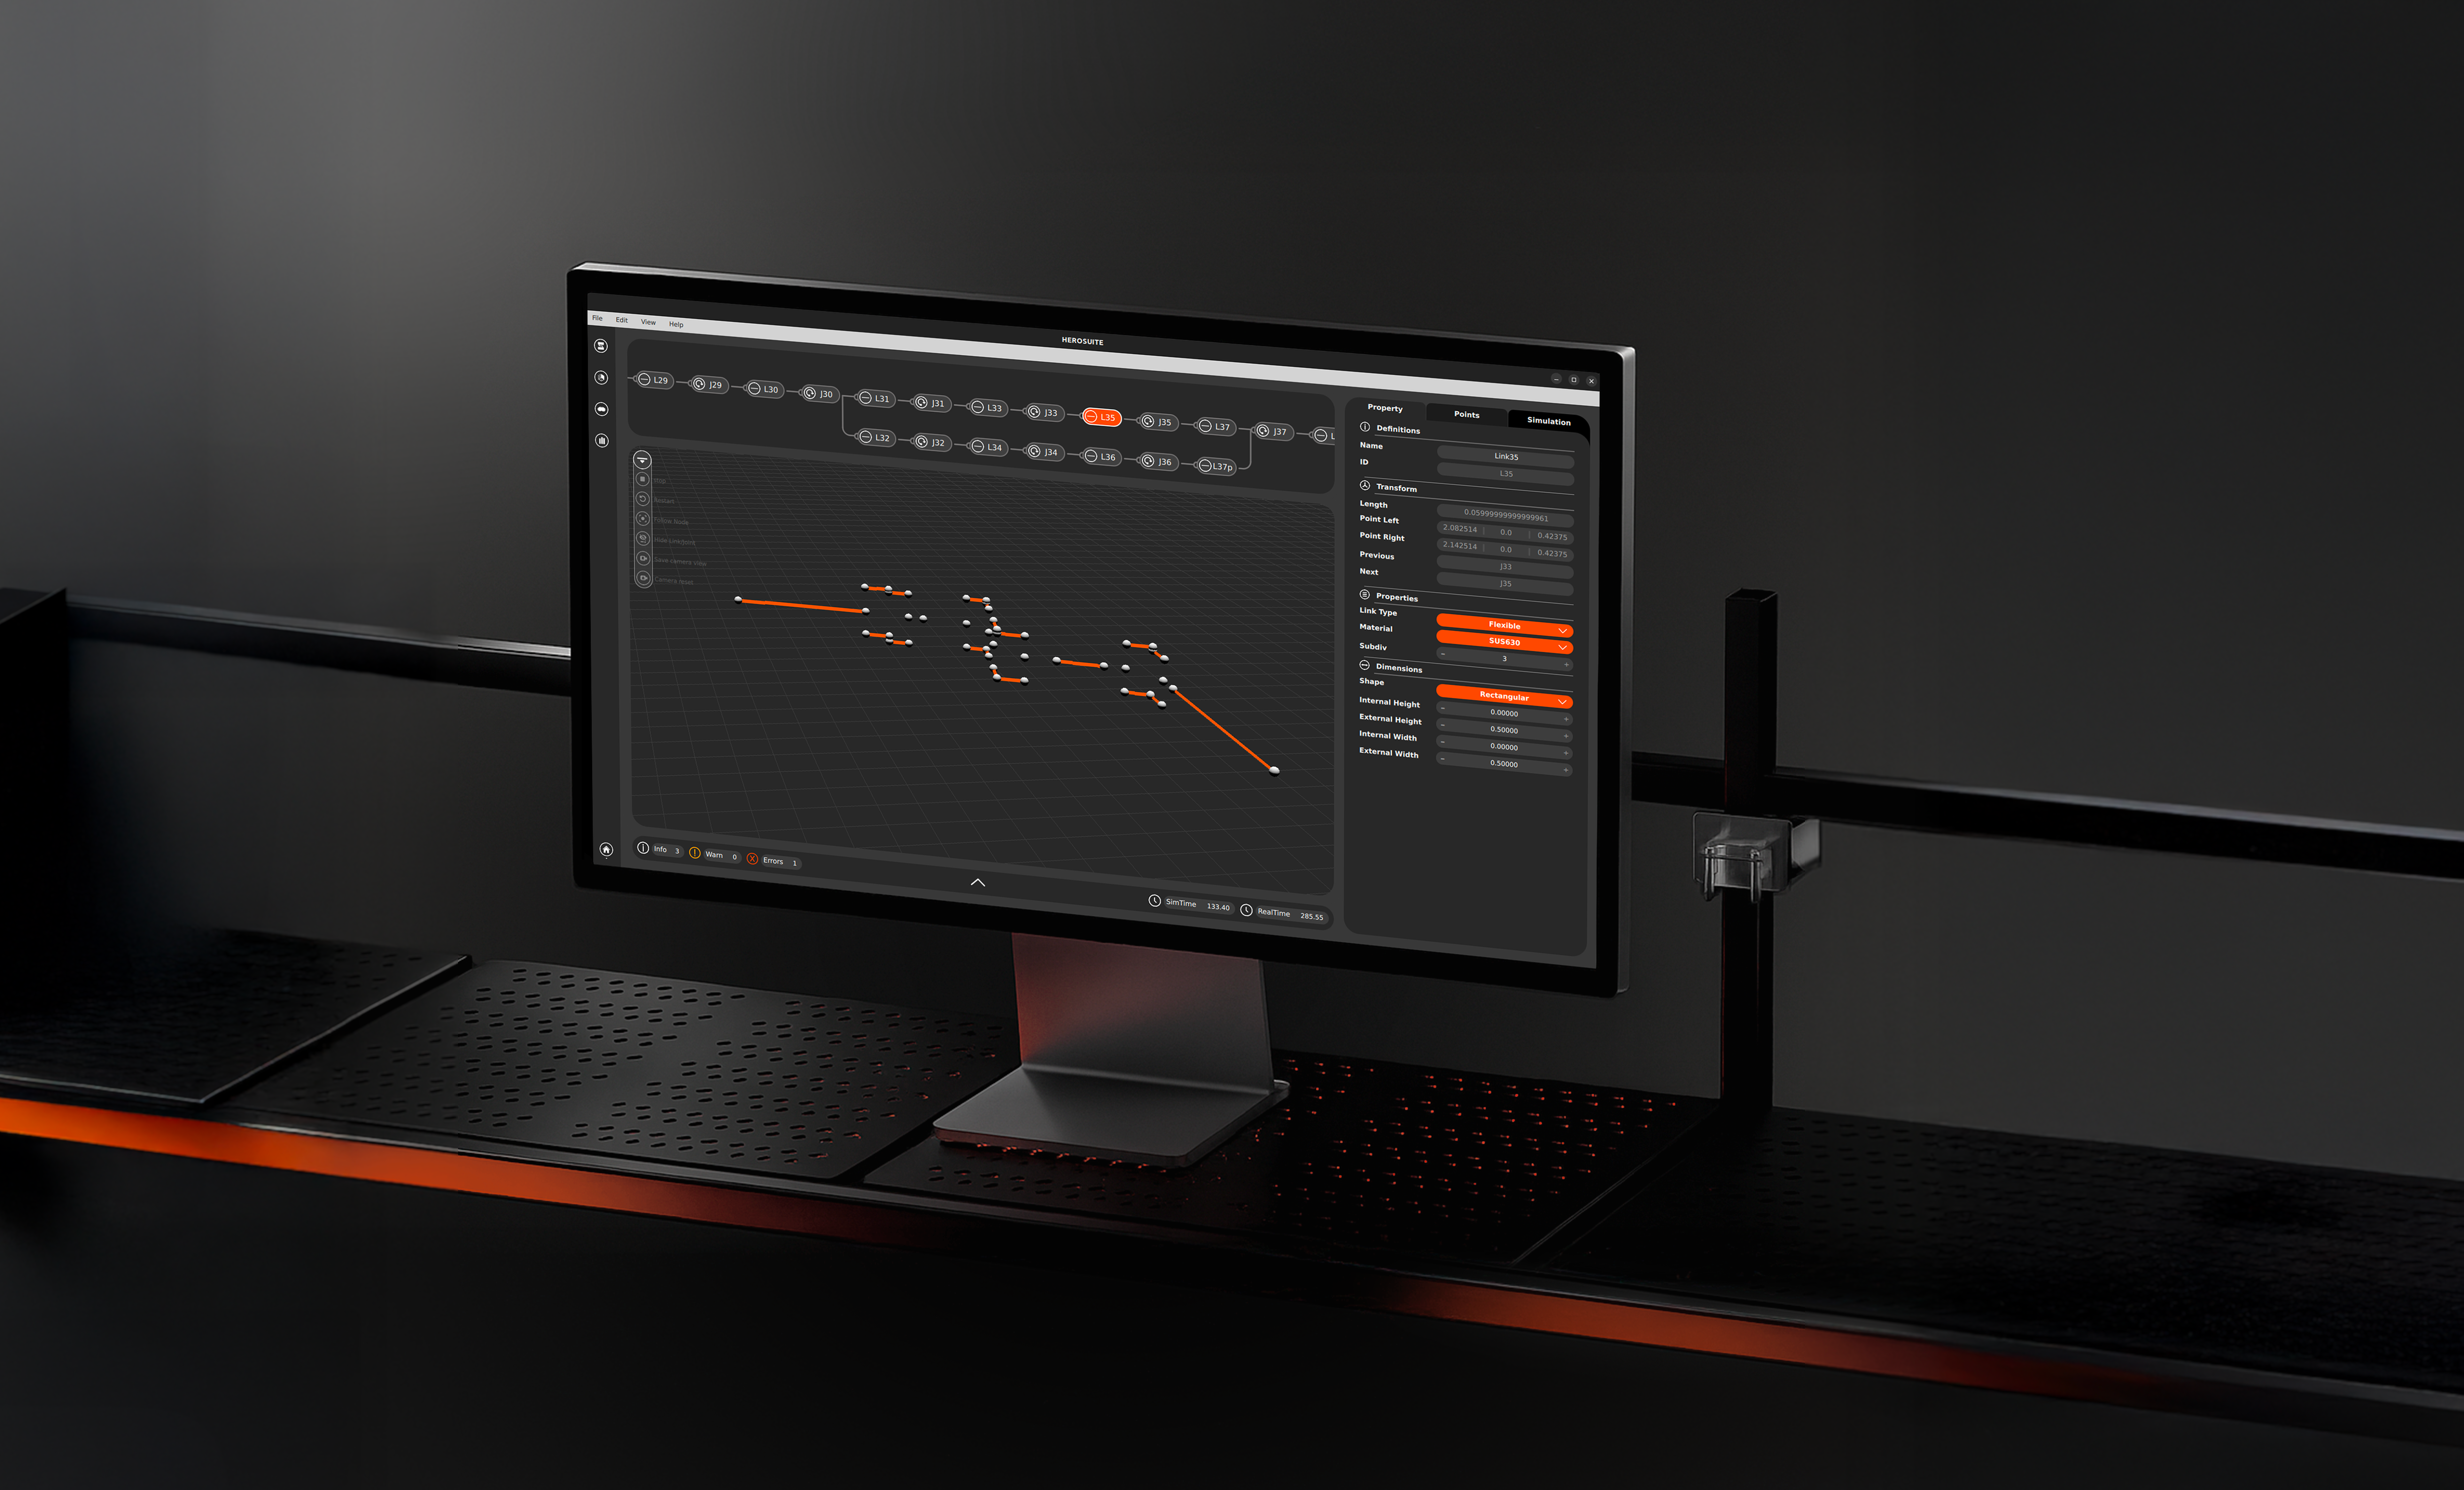
Flexible Dynamic Simulation
Robot simulation in the Control Room is performed by our proprietary dynamic simulation engine, developed for long-reach, continuum and flexible robotic systems. Unlike conventional rigid-body simulators, the engine models the robot as a deformable structure: link flexibility, structural deformation under load and vibration are computed in soft real time, together with rigid-body dynamics and contact.
02.
Collision Detection
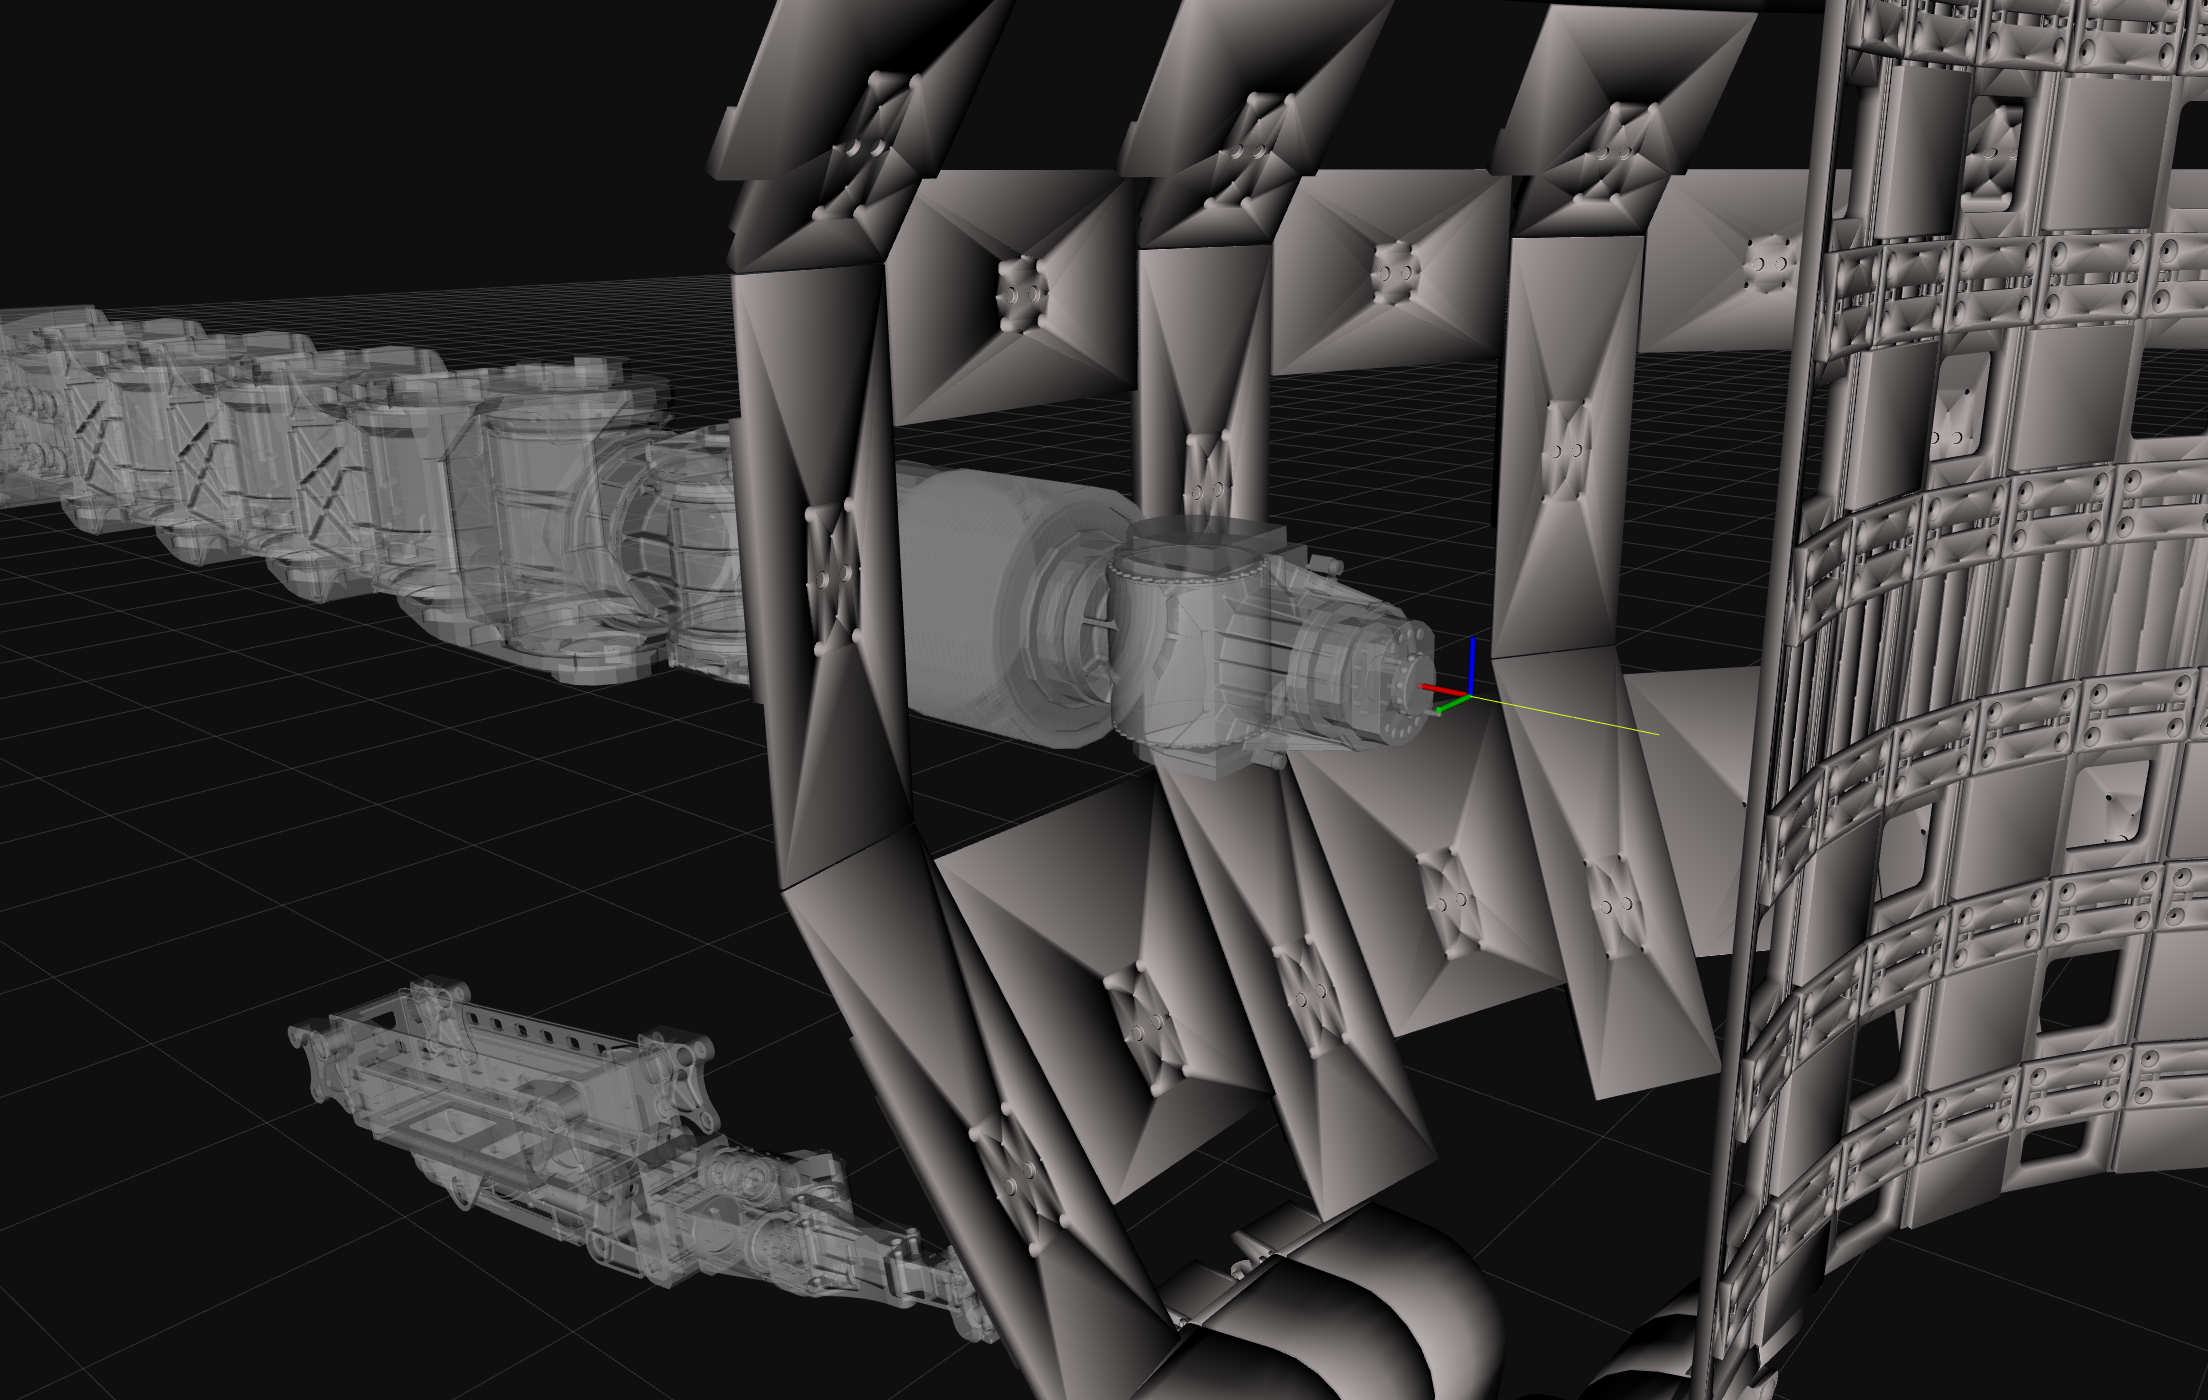
The collision module continuously computes the distance between the entire body of the robot, the surrounding objects and the environment, not only at the end-effector. The custom collision module achieves soft real-time update rates, with accurate meshes of robots and the environment, and multiple levels of detail. Within the 3D visualization, proximity levels are represented through a gradient color-coded system, allowing operators to immediately identify when two elements are approaching a critical distance. The collision module is also integrated with the safety system to safely stop autonomous movements or guide teleoperation under critical conditions.
Proximity color coding
Object color shifts as the distance to nearby elements decreases.
Safe separation. No action.
Approaching. Monitor motion.
Critical distance. Speed reduced.
Collision risk. Safe stop triggered.
03.
Virtual Reality
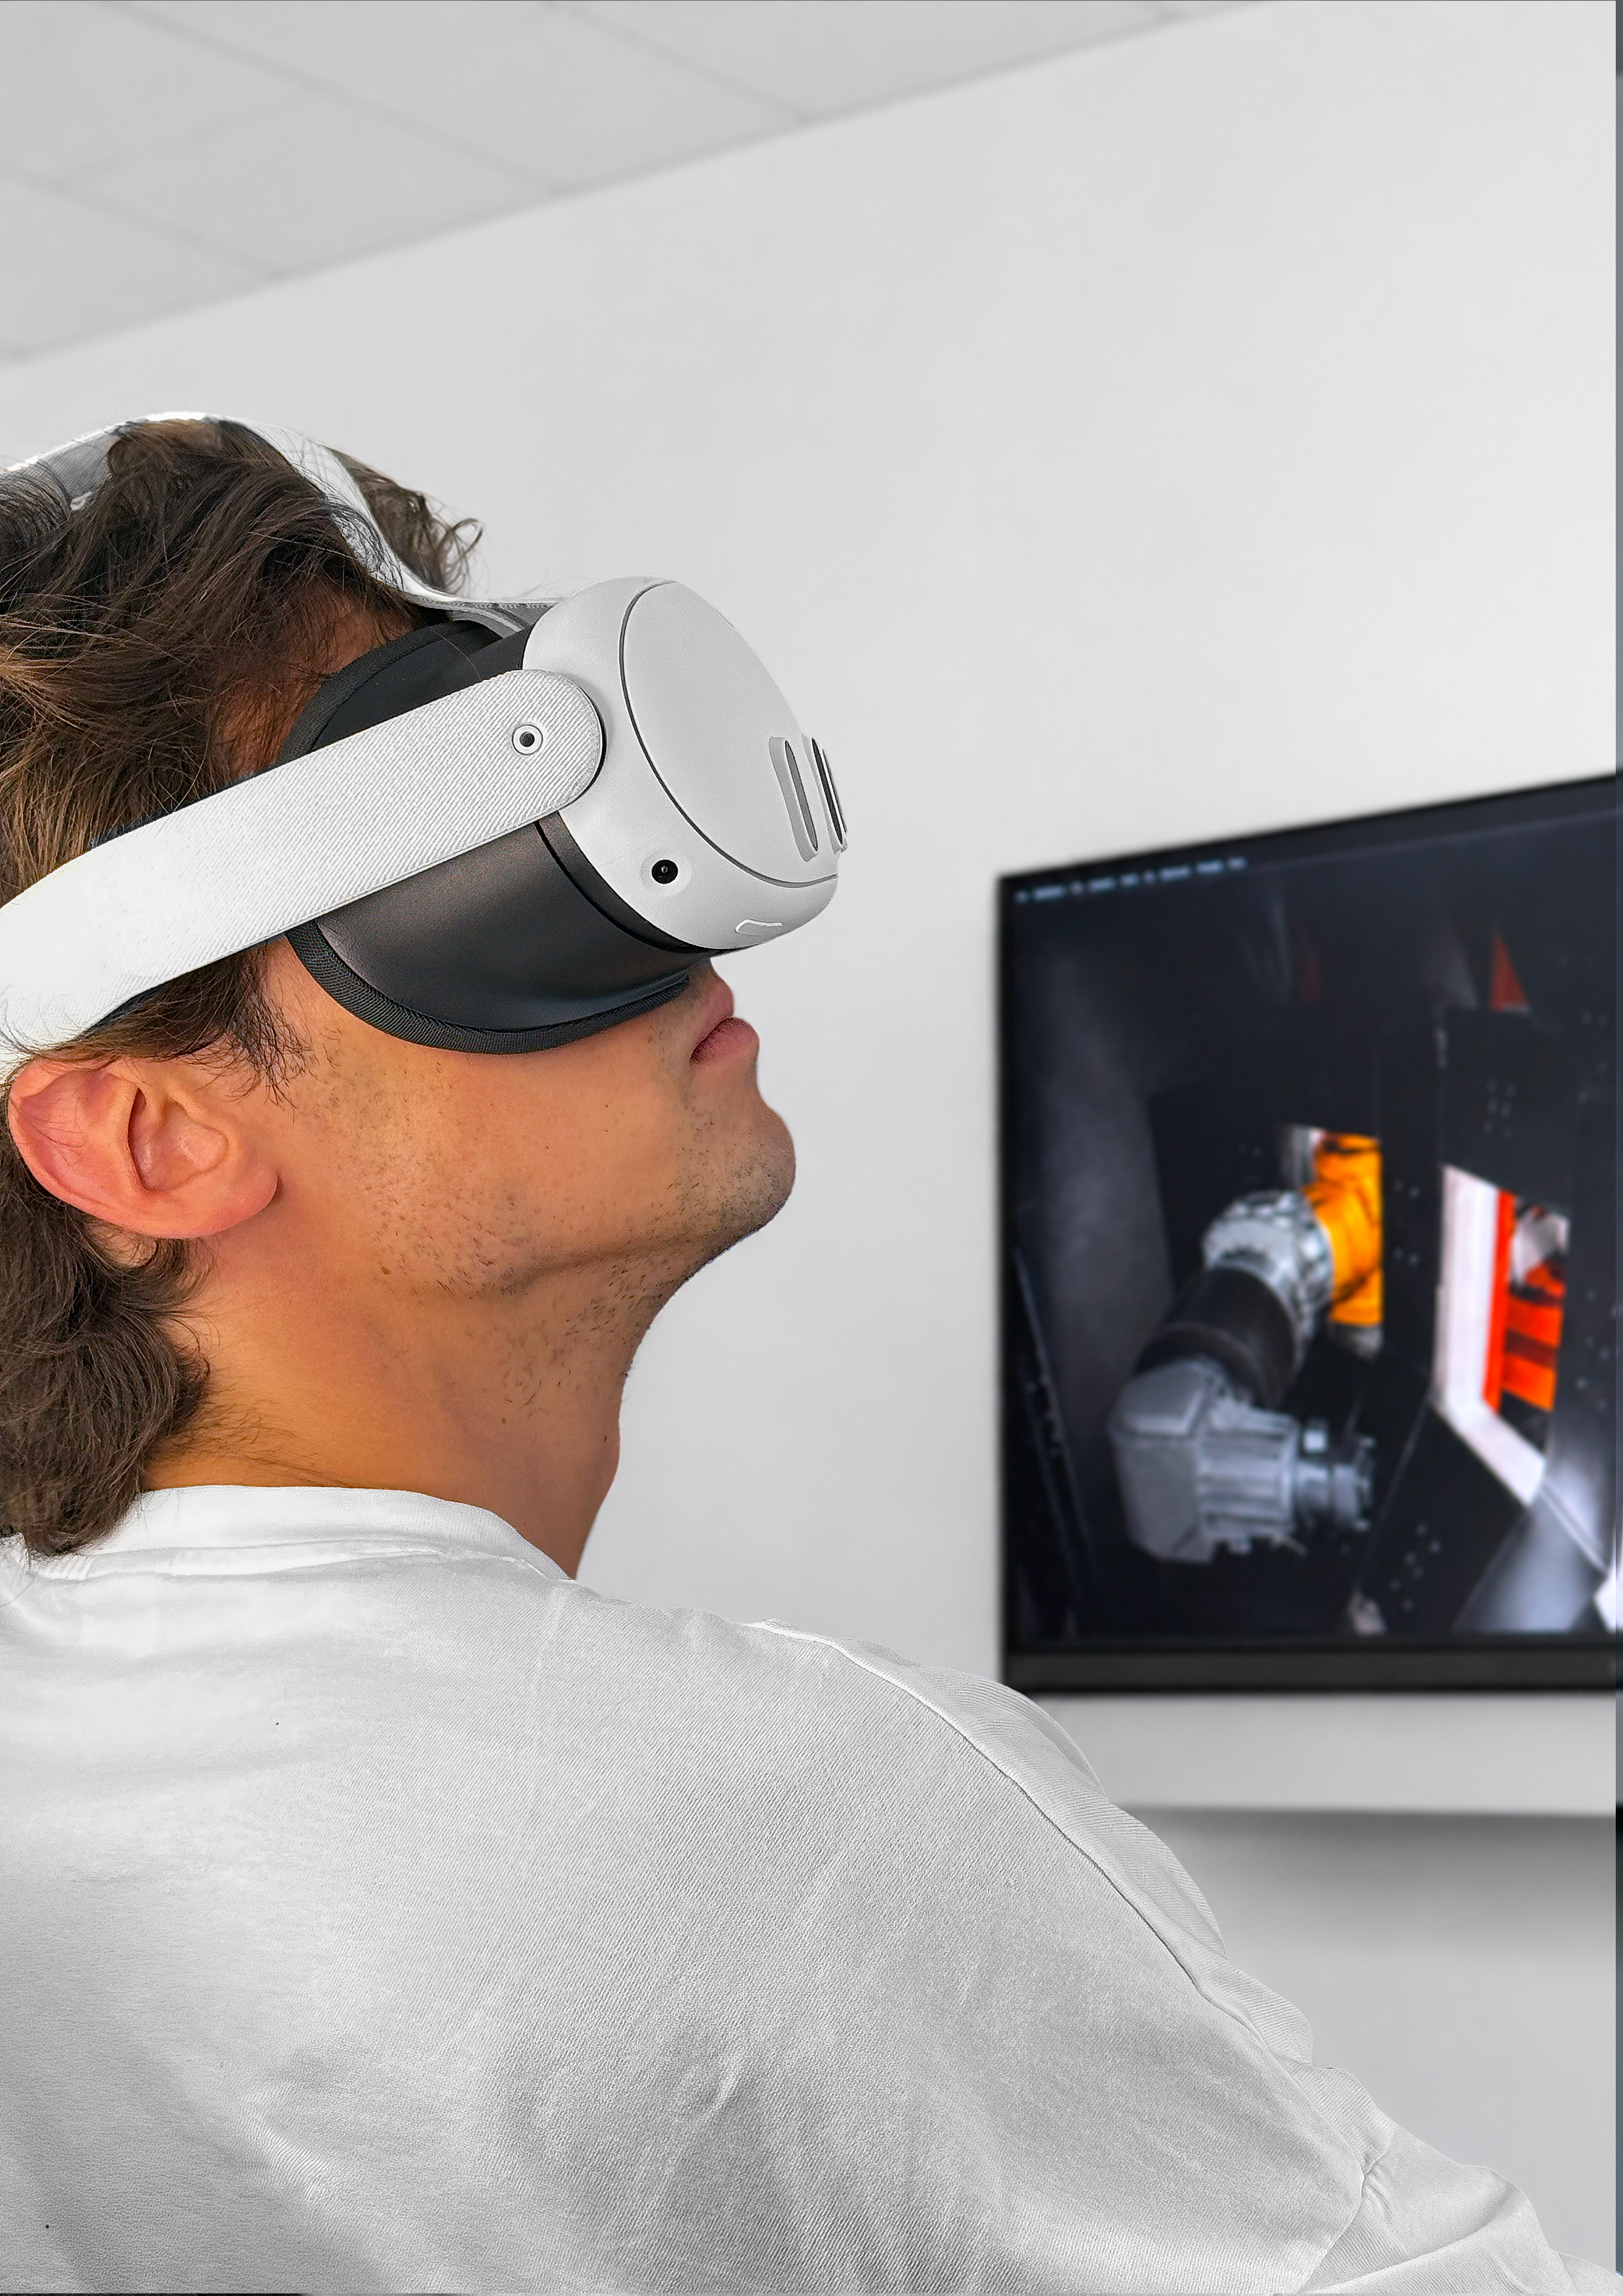
Planned and ongoing operations are validated and supervised through immersive Virtual Reality sessions. Operators navigate the digital twin from any point of view, using real and virtual cameras. Using a VR headset and joystick inputs, operators can move in the environment, assess clearances, identify critical conditions ahead of time, and follow the mission during execution, supervising the digital twin.
04.
Haptic Teleoperation
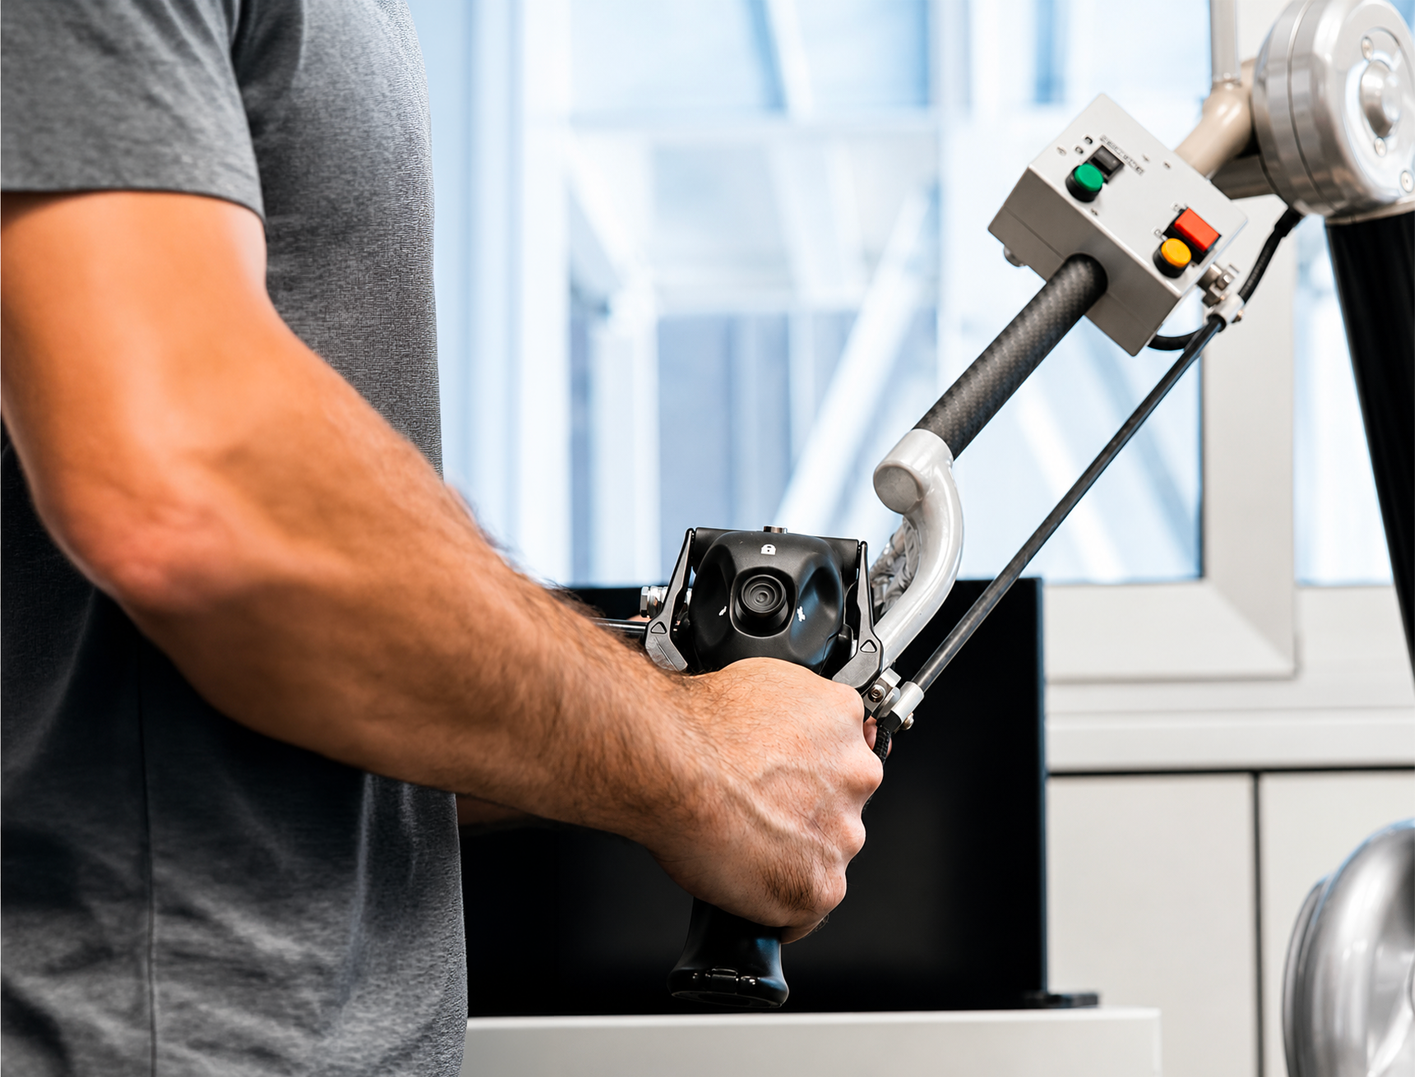
The Control Room integrates high-fidelity haptic interfaces to provide intuitive, six-degree-of-freedom teleoperation with realtime force feedback, enabling operators to perform complex remote manipulation tasks with increased precision and confidence. Advanced haptic assistance algorithms augment manual control by generating virtual interaction forces based on the robot's environment, digital twin, and task context.
Virtual fixtures, configurable safety boundaries, and collision avoidance algorithms create directional guidance forces that prevent the robot from entering restricted regions or contacting surrounding structures, significantly reducing the risk of accidental collisions. Task-specific guidance algorithms assist operators during precision operations such as alignment, insertion, centering, docking, and constrained object manipulation by actively guiding the end-effector along desired trajectories while preserving operator control.
05.
Motion Planning
Trajectory generation and validation for complex redundant robotic systems: the operator specifies the action to perform, and the module generates the robot configurations that achieve it, optimises the motion between them and validates the result on the digital twin.
Redundancy-aware IK
Custom inverse kinematics solvers handle redundancy, closed-chain mechanisms and coupled joints from end-effector goals.
Optimised trajectories
Collision-aware planning generates smooth, dynamically feasible and time-optimal motions within operational constraints.
Digital twin validation
Every motion is previewed in the twin to verify interactions and detect collisions or singular configurations.
06.
Safety and Diagnostics
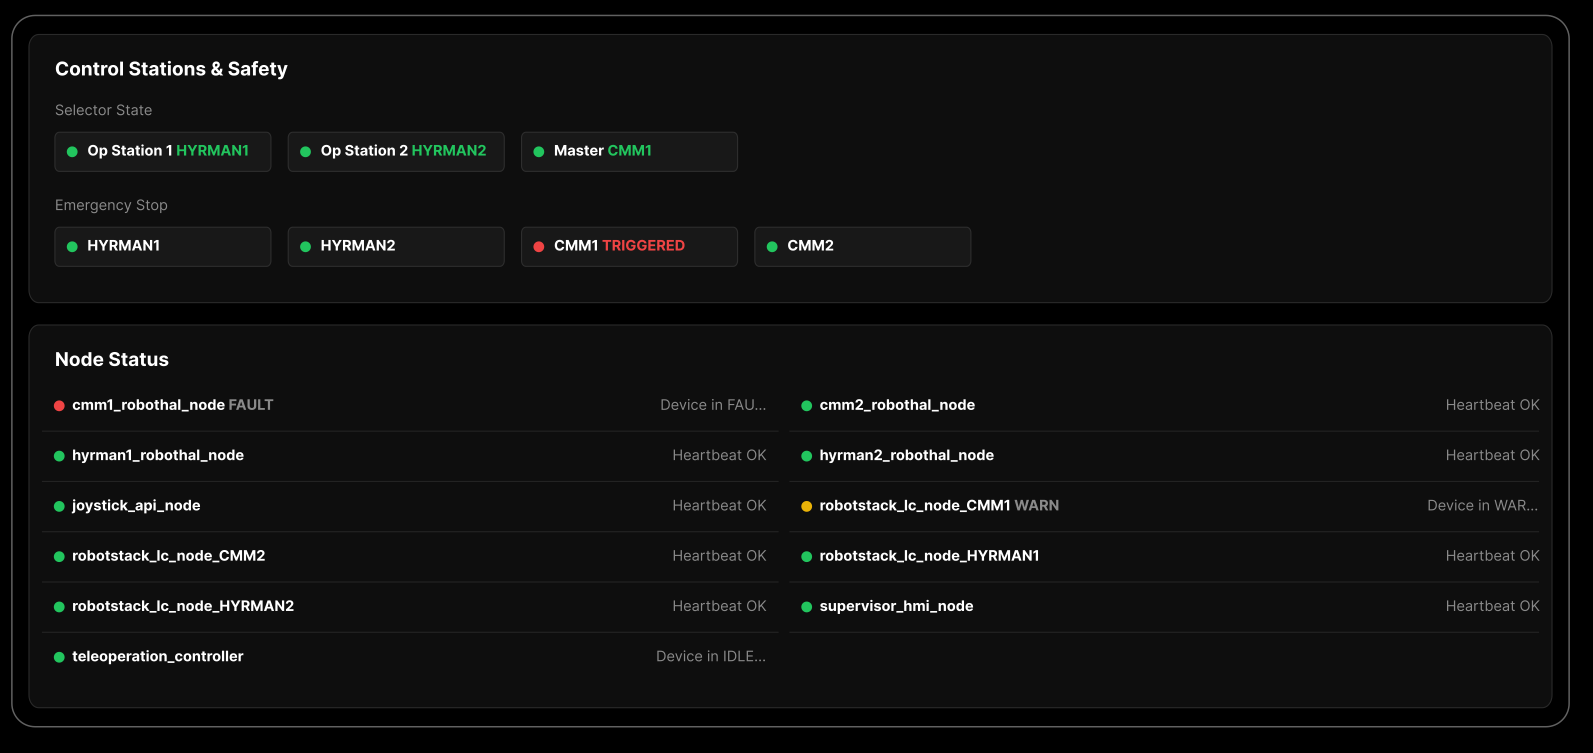
A safety PLC is connected to programmable hardwired emergency-stop devices placed on each operator station, to safely stop each robot, ensuring intervention in the event of a critical condition. The dedicated diagnostic interface continuously monitors internal system status, safety signals, alarms and operational errors, enabling operators to quickly identify faults, diagnose events through logs, and safely restore operating conditions.
To ensure continuous operation, the Control Room is equipped with an industrial Uninterruptible Power Supply (UPS) that protects critical computing, networking, and control infrastructure. The UPS provides sufficient backup power to maintain system availability during short power outages and enables the controlled shutdown of all the systems, preventing data loss, preserving system integrity, and ensuring the safe termination of ongoing robotic operations.
07.
Procedure Planning
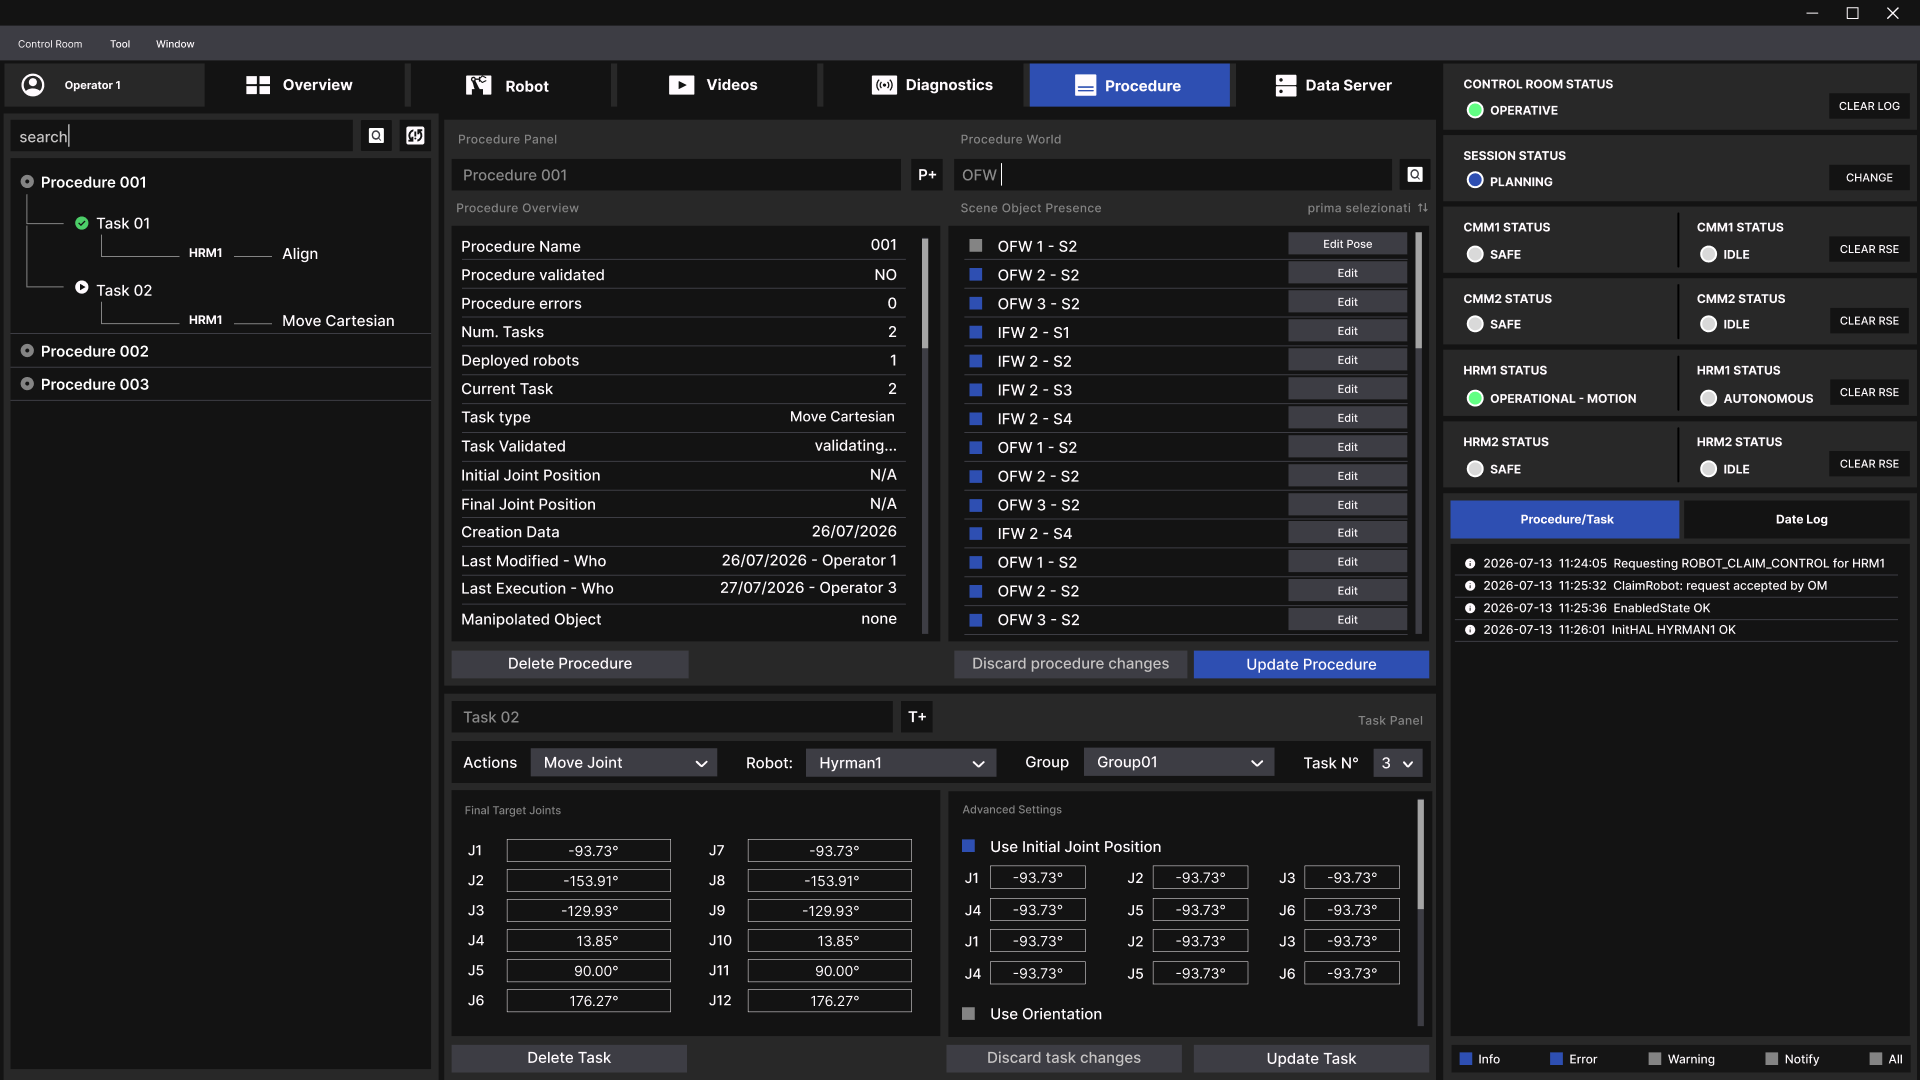
The Procedure Panel enables operators to create and configure robotic procedures by combining predefined tasks through an intuitive visual interface. Robot movements, actions and operational sequences can be selected and arranged without writing code, allowing users with no programming expertise to safely and efficiently control the robotic system.
08.
Data Management
The Control Room Data Server centralizes the collection, storage and organization of operational data generated by the robotic systems. It manages telemetry, system logs, alarms, task information and session recordings, ensuring that all relevant data remains accessible and traceable. This infrastructure supports real-time monitoring, post-operation analysis, report generation and reliable documentation of every robotic procedure.
Cyber Security
The cybersecurity system is designed to safely manage complex and distributed networks. Network access is controlled, allowing only authorized and verified devices to connect. Users are managed through defined roles and permission levels, so each person can access only the data, functions, and resources needed for their tasks. The system also supports connection monitoring and access tracking to improve overall network security.
09.
Sensing Integration
The Control Room provides a unified data integration framework capable of acquiring, synchronizing, and visualizing heterogeneous sensor sources from the robotic systems and surrounding environment. Real-time data streams from cameras, robot telemetries, tracking systems and external equipment are integrated in the operator interfaces.
By combining live perception data, recorded data, and system diagnostics within a single environment, the Control Room supports advanced inspection, maintenance and intervention tasks, while improving operational efficiency and safety in nuclear power and complex scenarios.
Range
One control room, several robots.
The control room is modular and independent: the same platform can be configured on different robots, machines and missions, and can upgrade manipulators that are already installed without replacing the robotic platform. These are the robots it has been applied to.
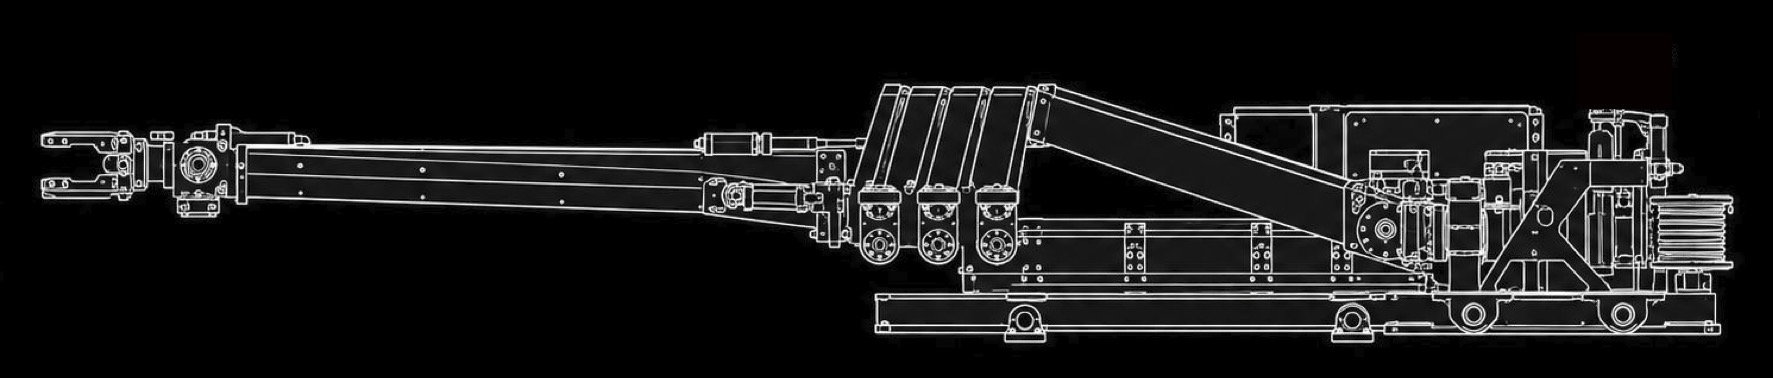
2,5M
Roman
Consorzio RFX
8,3M
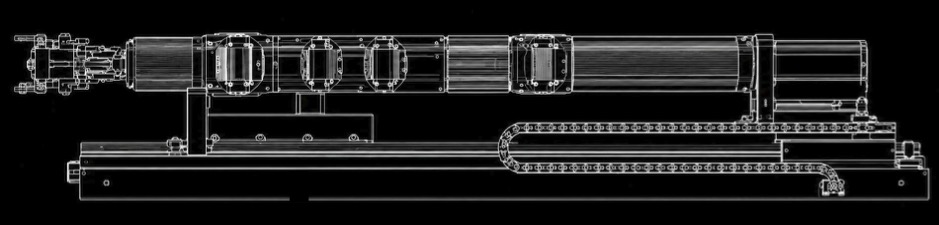
Hyrman
ENEA
14M
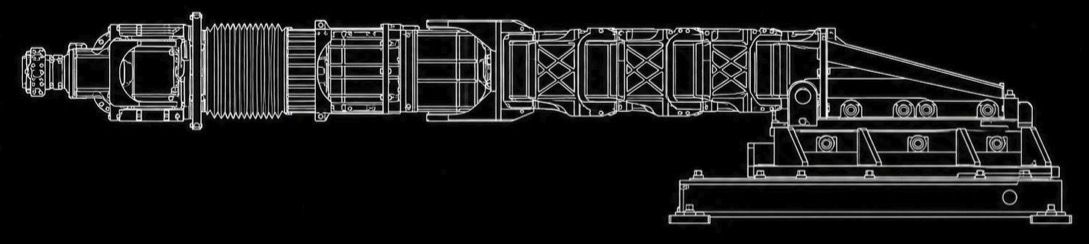
TARM
UKAEA
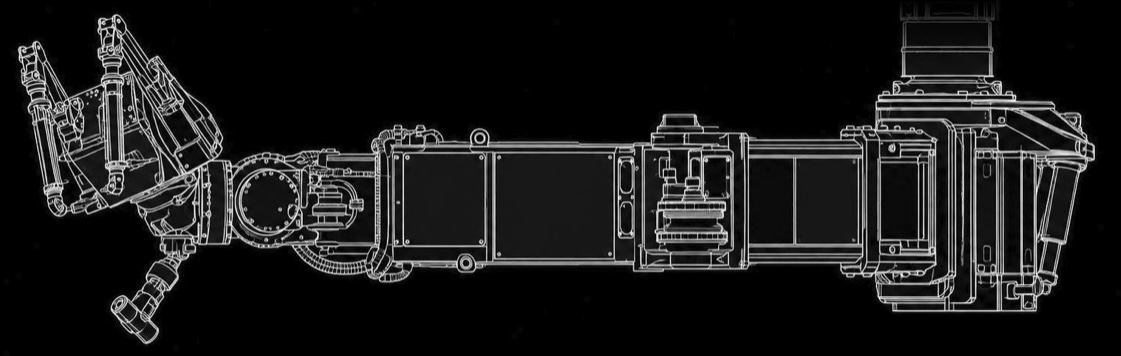
24M
Fukushima Daiichi
TEPCO
In the field
Where the control room has been deployed.
LongOps
UKAEA and TEPCO
LongOps is a UK and Japan programme funded by UK Research and Innovation, the Nuclear Decommissioning Authority and TEPCO Holdings, aimed at faster and safer decommissioning at Fukushima Daiichi and at the JET fusion reactor.
For the programme we developed the modelling algorithms, the digital twin and the vibration control of long-reach flexible manipulators: the TARM arm at UKAEA and the Fukushima Daiichi system. Two capabilities of the control room went into service there, dynamic simulation and vibration control, reducing vibration by up to 97%, with no additional sensors on the robot.
DTT
ENEA
DTT, Divertor Tokamak Test facility, is a fusion experiment under construction at the Frascati ENEA Research Center. DTT plays a leading role in fusion research, the main aim being to explore alternative solutions for the extraction of the heat generated by the fusion process.
The Control Room software is applied by ENEA to plan, simulate and remotely operate the robotic systems that will work inside the reactor.
standards
Built on open standards
Framework based on
Compatible with
Tested with Human Interaction Devices
Partners & clients