the challenge
The challenge of nuclear robotics
Operating in confined, hard-to-reach environments with high precision and zero tolerance for failure.
Vibration and flexibility
Long, slender structures are prone to vibration, reducing accuracy and increasing collision risk.
Sensor deployment limits
Complex nuclear environments limit sensor coverage, leaving critical areas unobserved.
Restricted access
Limited entry points and narrow passages make deployment extremely difficult and complex.
Instance
Robot for RFX-mod2 reactor
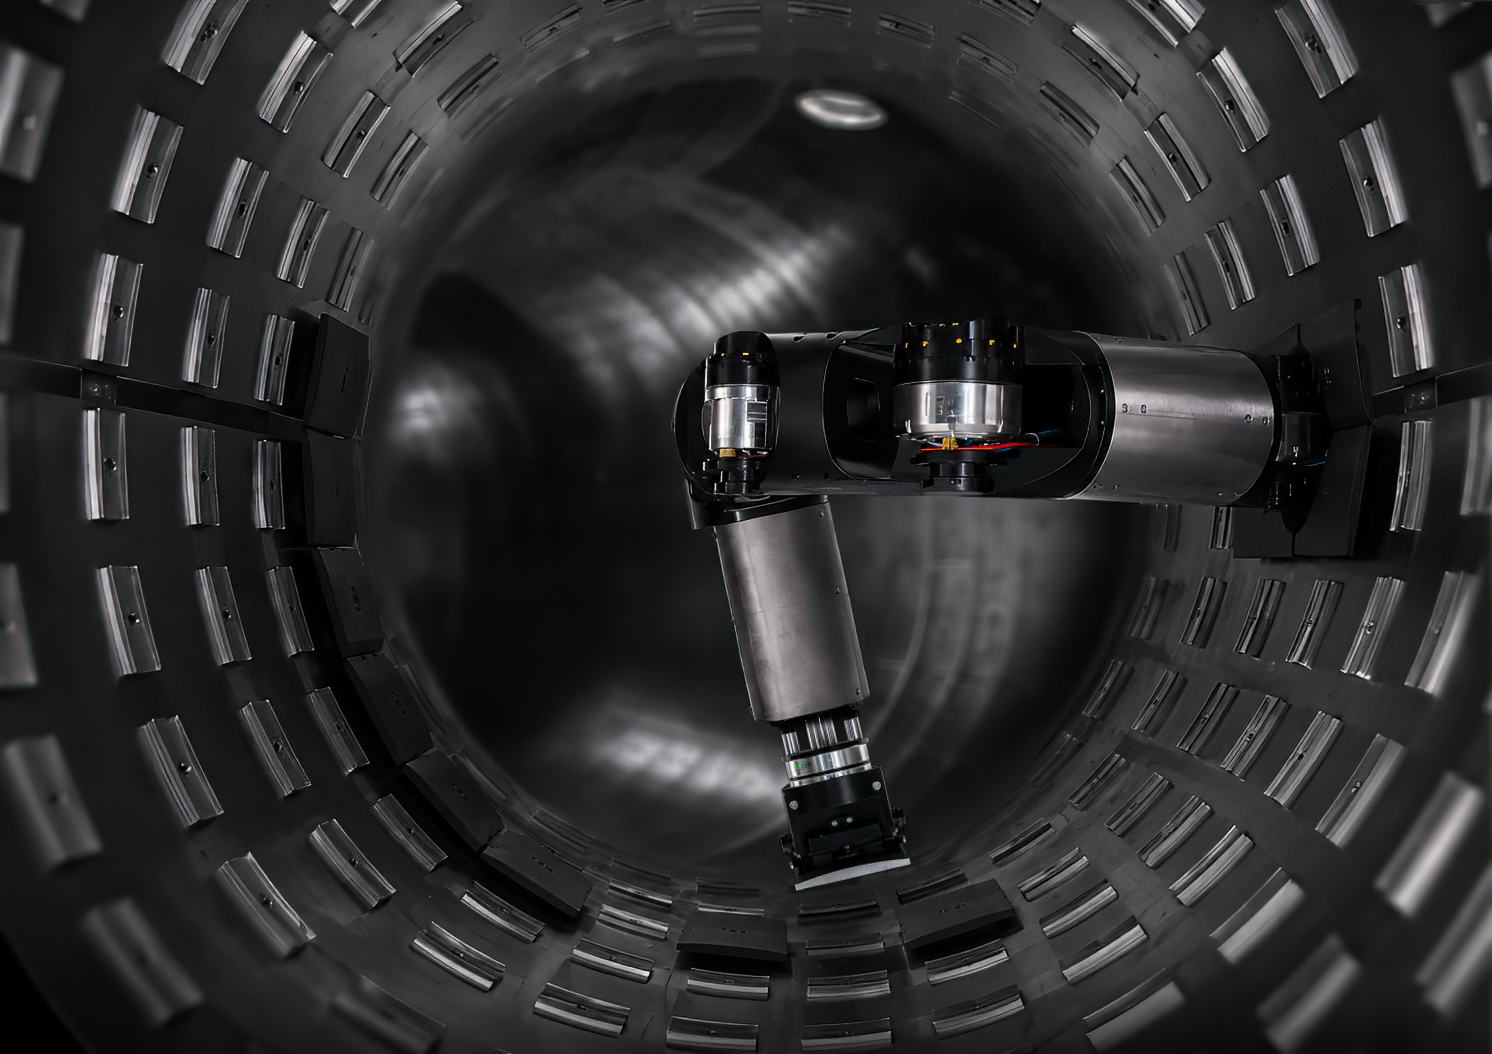
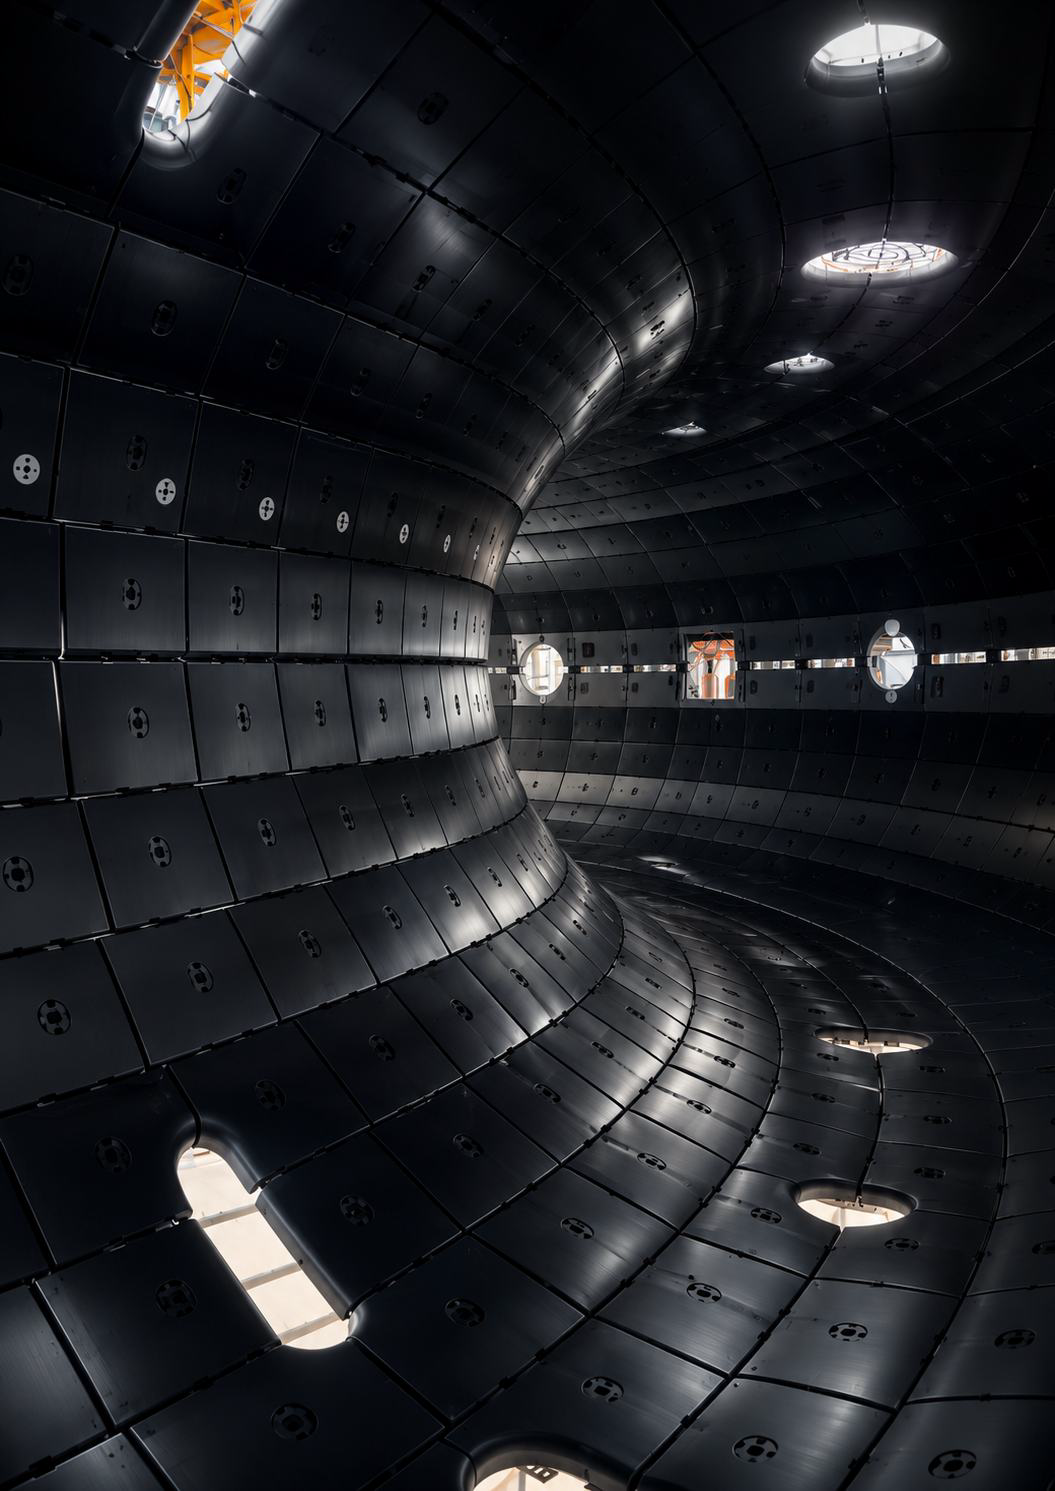
RFX-mod2 machine first wall is composed of graphite tiles directly exposed to the plasma, which are damaged over time and therefore require inspection and replacement. Since the vessel is fully enclosed and inaccessible to human operators, maintenance activities must be performed remotely.
Roman provides the dexterity, precision and force required to safely remove and replace the tiles, delivering an axial force of over 200 N at the end-effector.
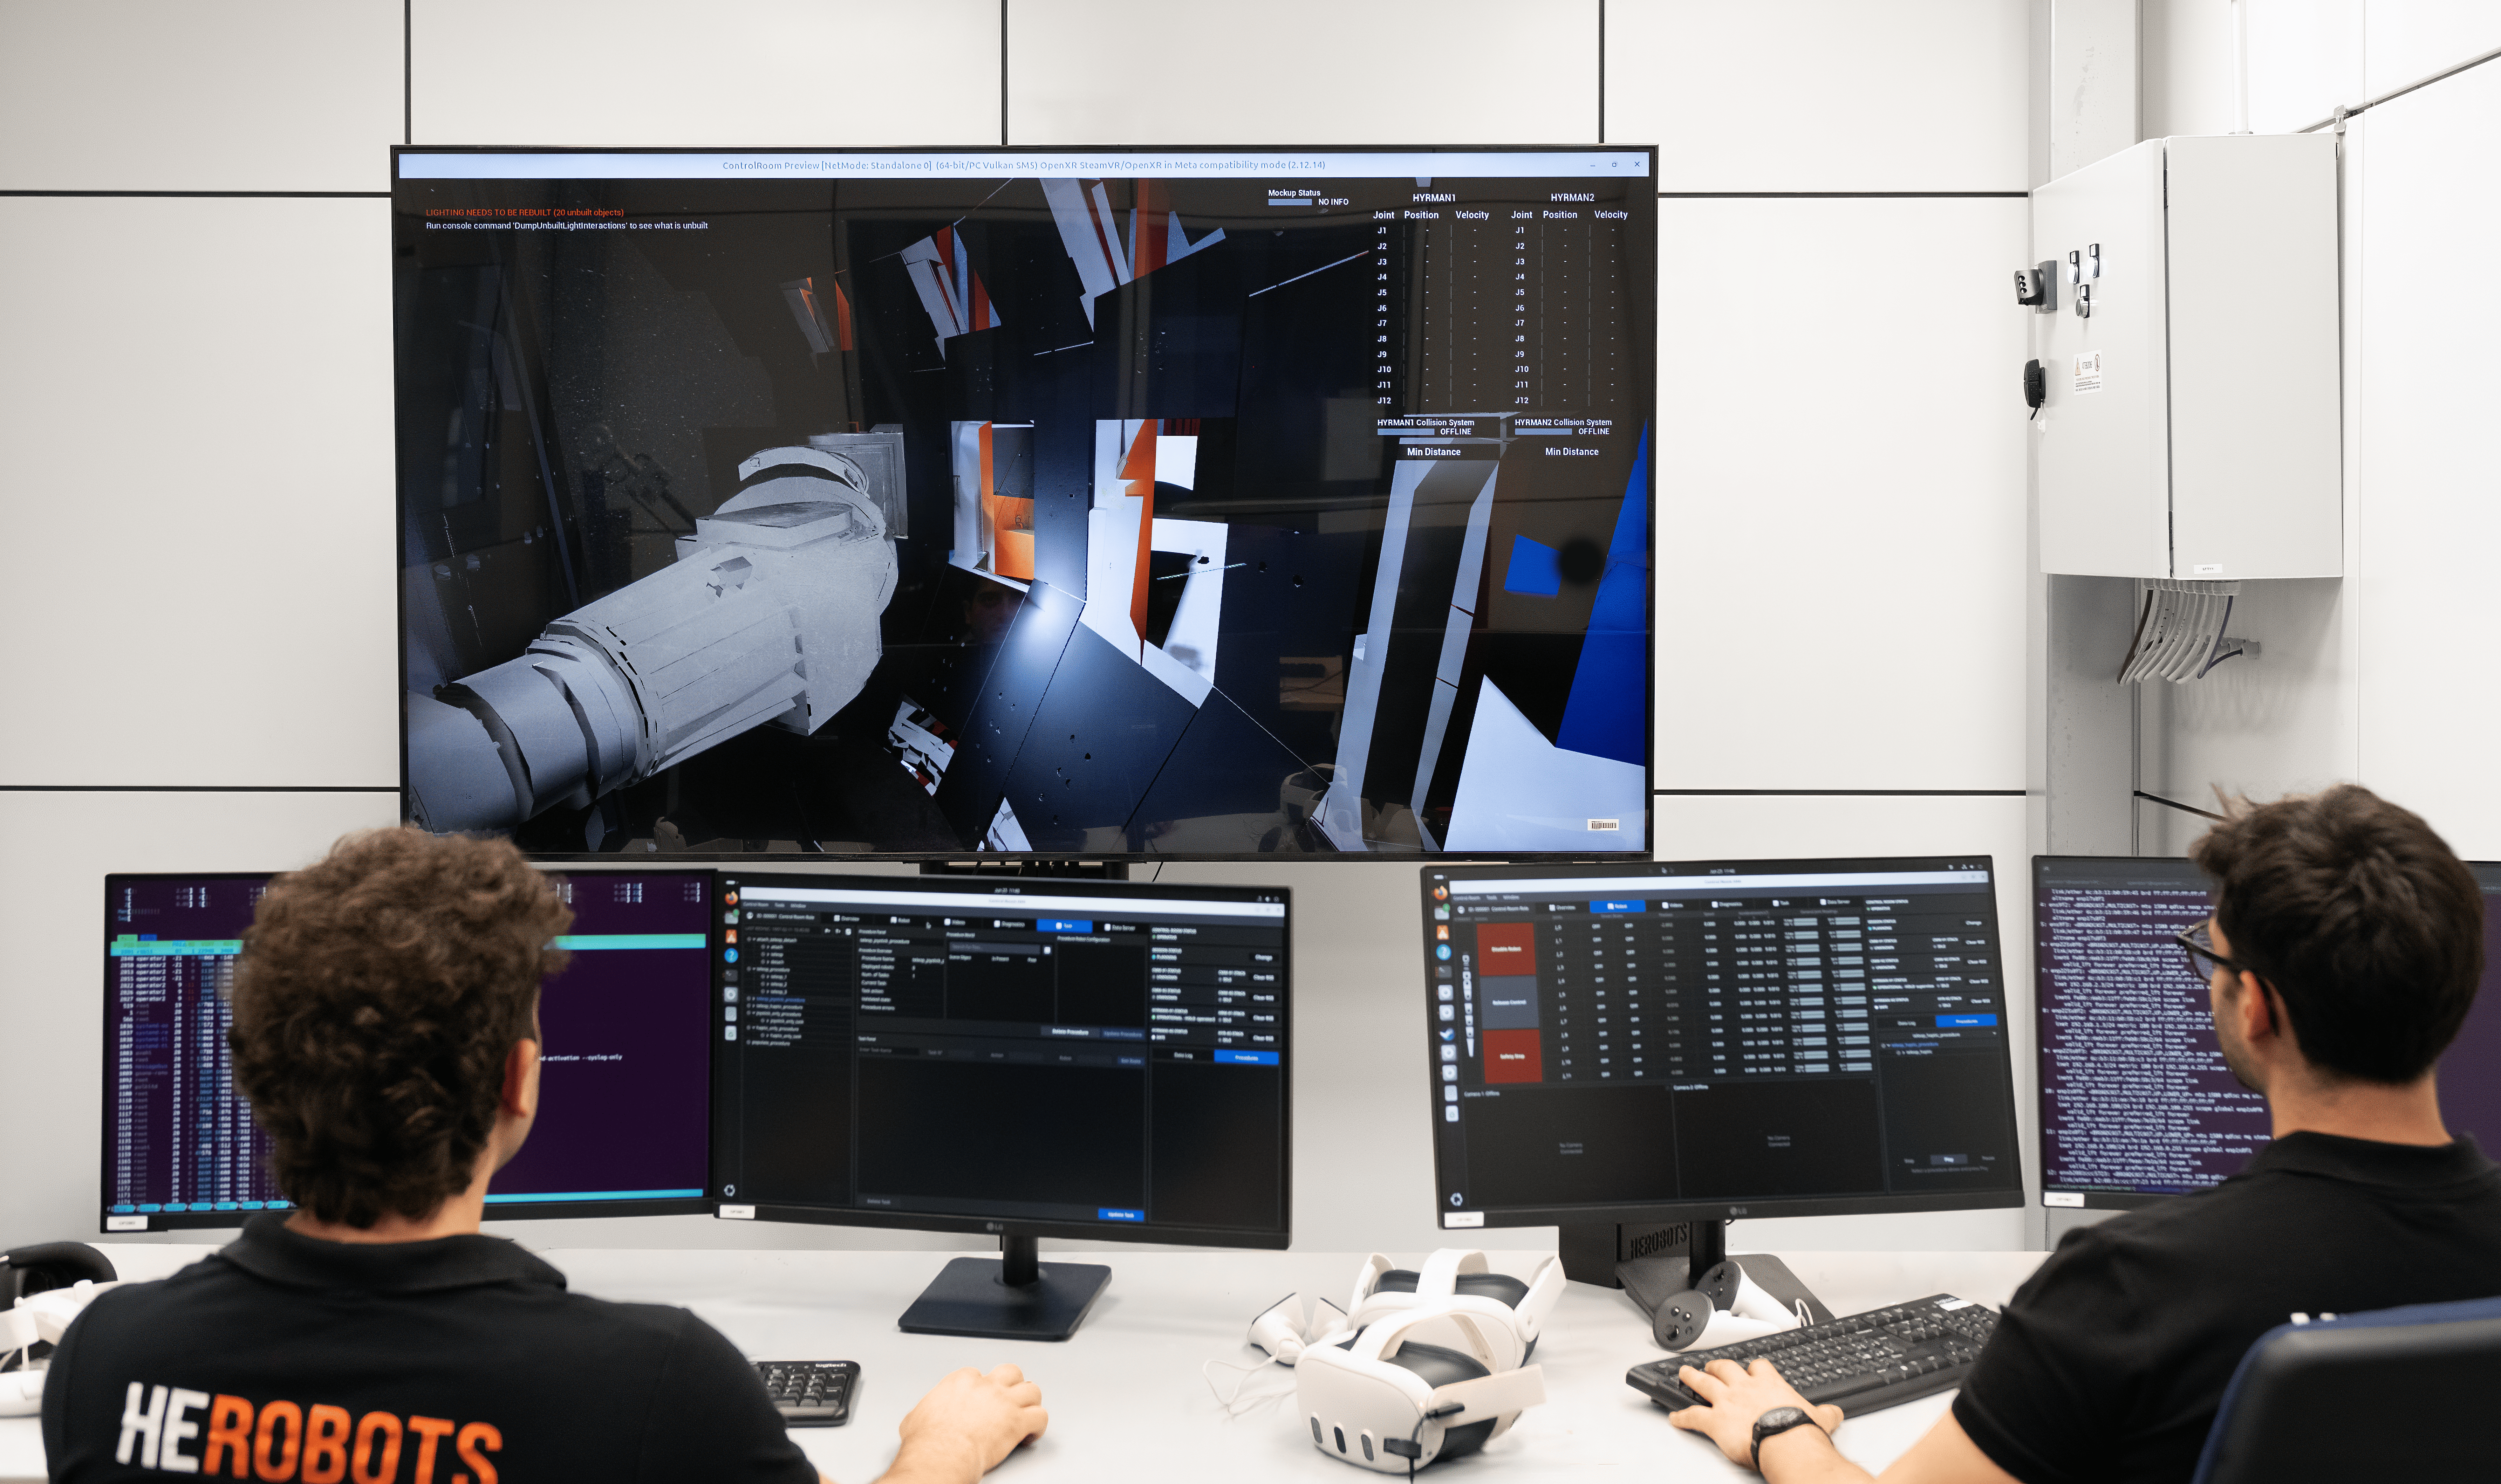
Because direct external visibility is not possible, the system supports the reconstruction of the internal environment to improve operational awareness and assist task execution. Its dedicated mechanical architecture enables safe movement within the confined vessel, minimizing collision risks throughout the procedure.
Remote operation
Inspection, maintenance and manipulation.
Small openings
Compact architecture reaches areas closed to conventional systems.
Modular design
Reconfigurable for different geometries, access constraints and tasks.
Asset availability
Less maintenance downtime, higher availability and operational efficiency.
roman
The robot arm
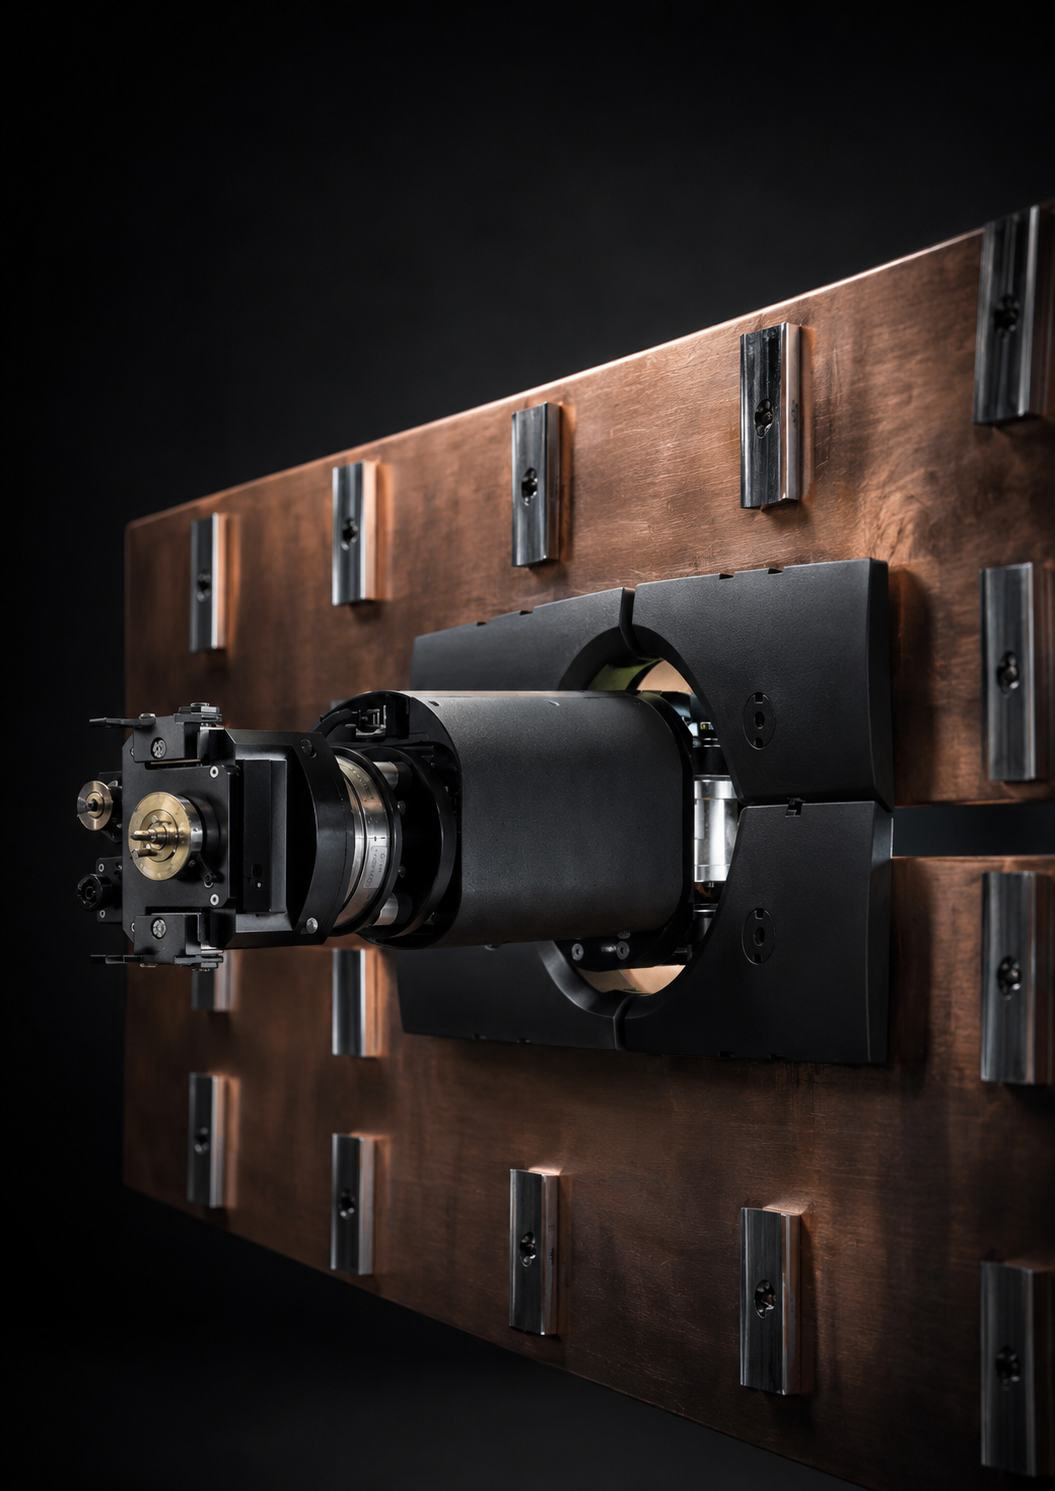
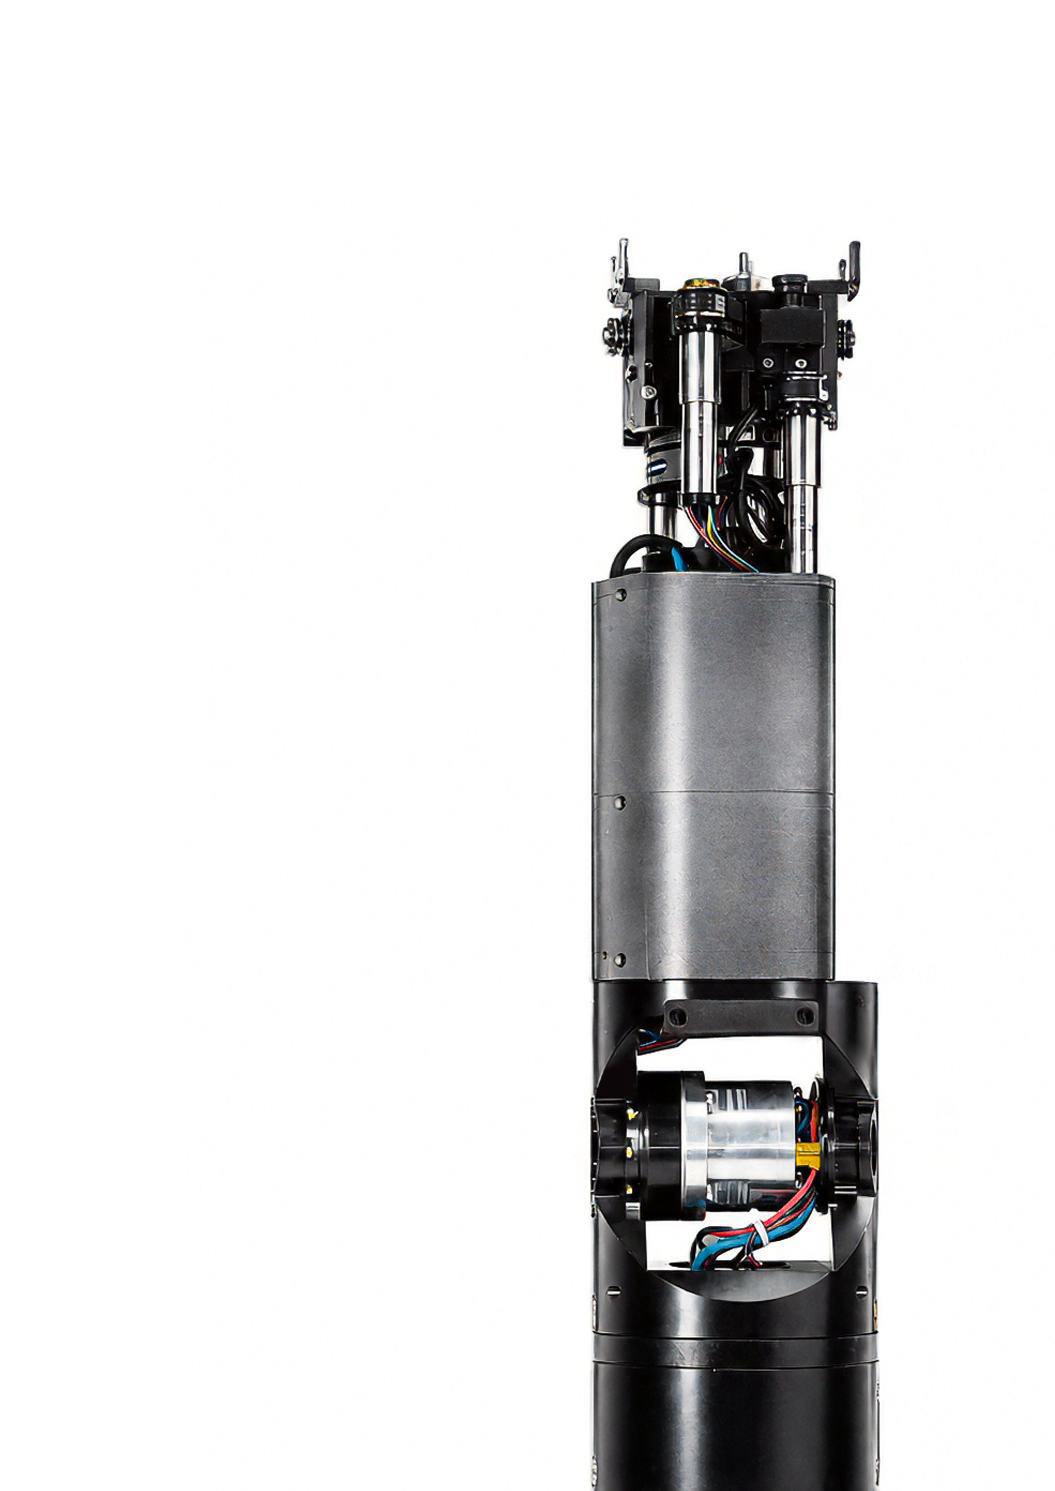
The robotic arm is designed to operate inside RFX-mod2, a toroidal machine with a diameter of 5 m. Six degrees of freedom enable precise in-machine manipulation, covering a 40° toroidal sector from the access port.
A dedicated distal prismatic joint enables a push-pull interaction with the machine, and a base-mounted calibration device ensures the right configuration of the arm. The compact architecture integrates all electronics within the arm footprint and supports manual emergency recovery through a fully backdrivable design.
Designed for
Specifications
Main components
Axial force at the end-effector above 200 N. Full configuration available on request.
end-effector
TIGER
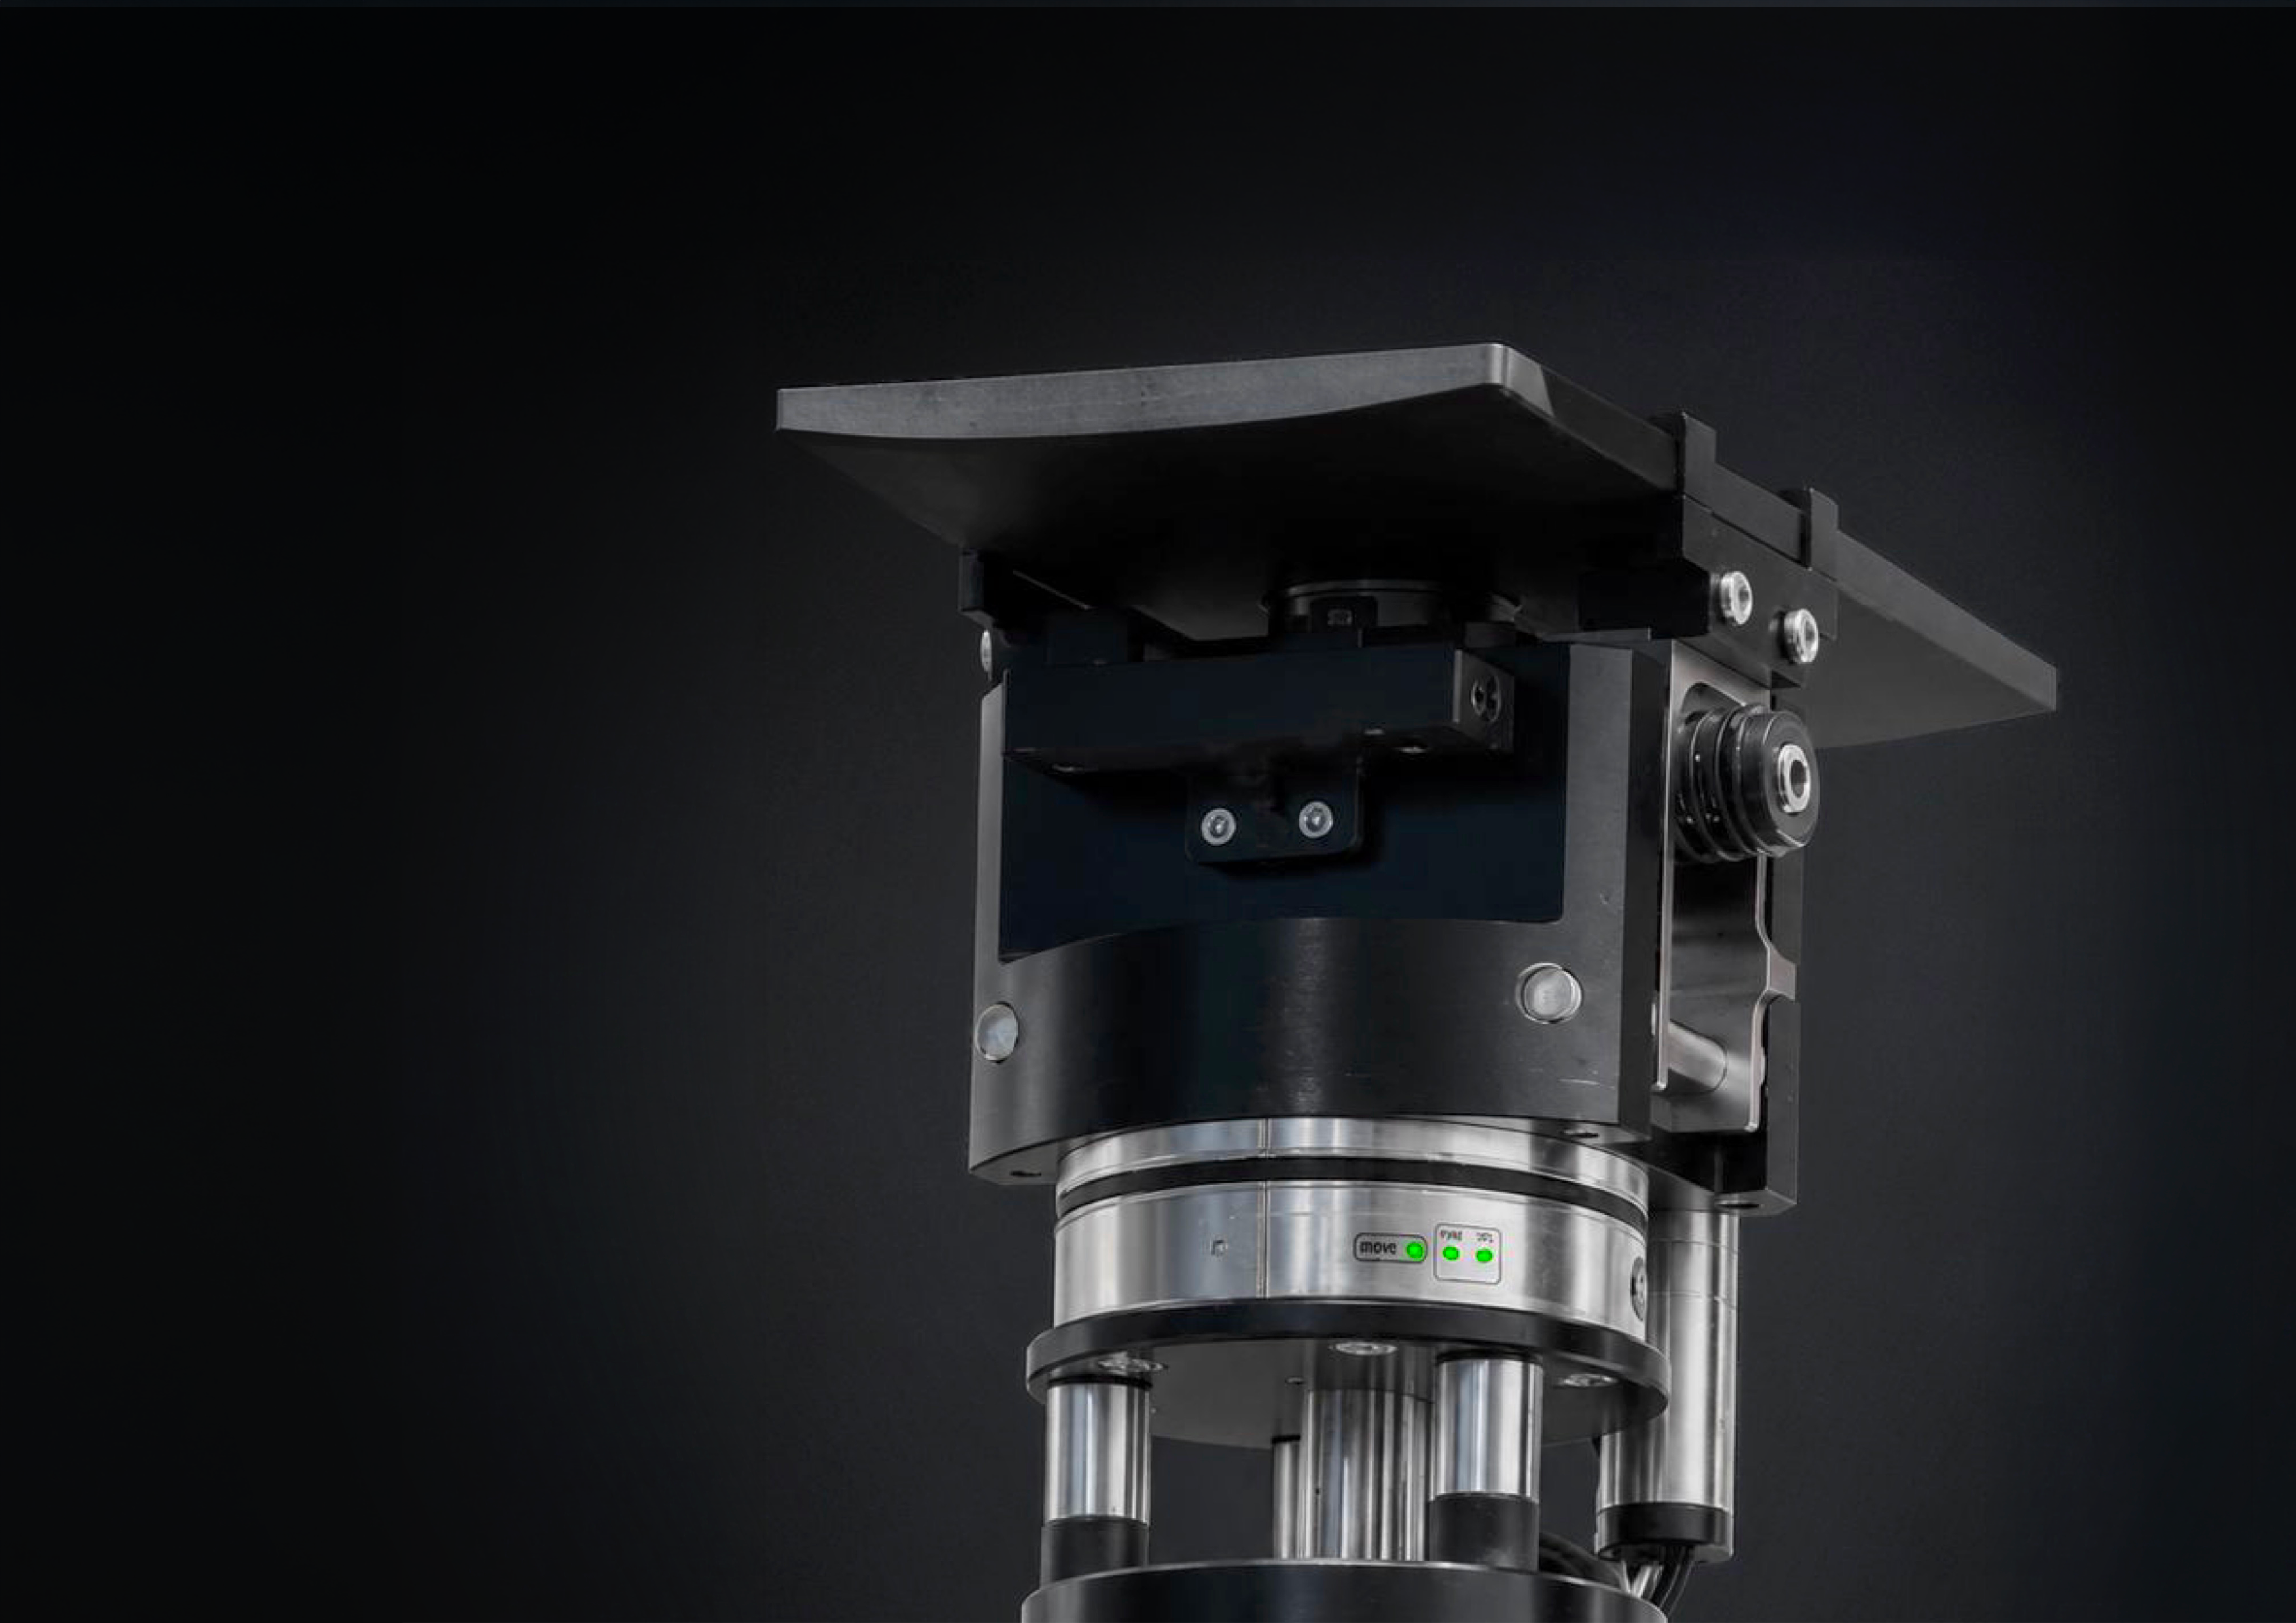
Enhanced end-effector for first-wall maintenance inside the RFX-mod2 nuclear reactor.
RGB camera
RGB camera for real-time visual inspection monitoring.
Depth camera
Camera for 3D point cloud environment reconstruction.
6 axis F/T sensor
F/T 6 axis for mapping the interactions with the environment.
Tip compensator
Passive compliant system that self-adjusts Roman tip pose.
Developed with