THE PROJECT
A new morphing technology for fabrics and leather.
RESHAPE develops a morphing technology for actuated smart surfaces, built from the integration of innovative materials, flexible sensing and distributed actuation. The technology applies to gripping systems that automate the Made in Italy processes requiring the delicate handling of fabrics and leather. The project advances the frontier between two sectors representative of Made in Italy, automation and textiles, and tests its proof of concept on a significant case study: the handling of leather panels.
THE CHALLENGE
Materials that deform under the force used to hold them.
Thin, deformable materials are hard to automate. Leather changes shape under the grip that lifts it, and current systems hold it rigidly at a few points, which leaves marks, causes localised damage and creases the panel in transport. In leather goods and automotive interiors a mark is a reject, so the operation has stayed manual.
HEROBOTS IN THE PROJECT
We designed the gripper.
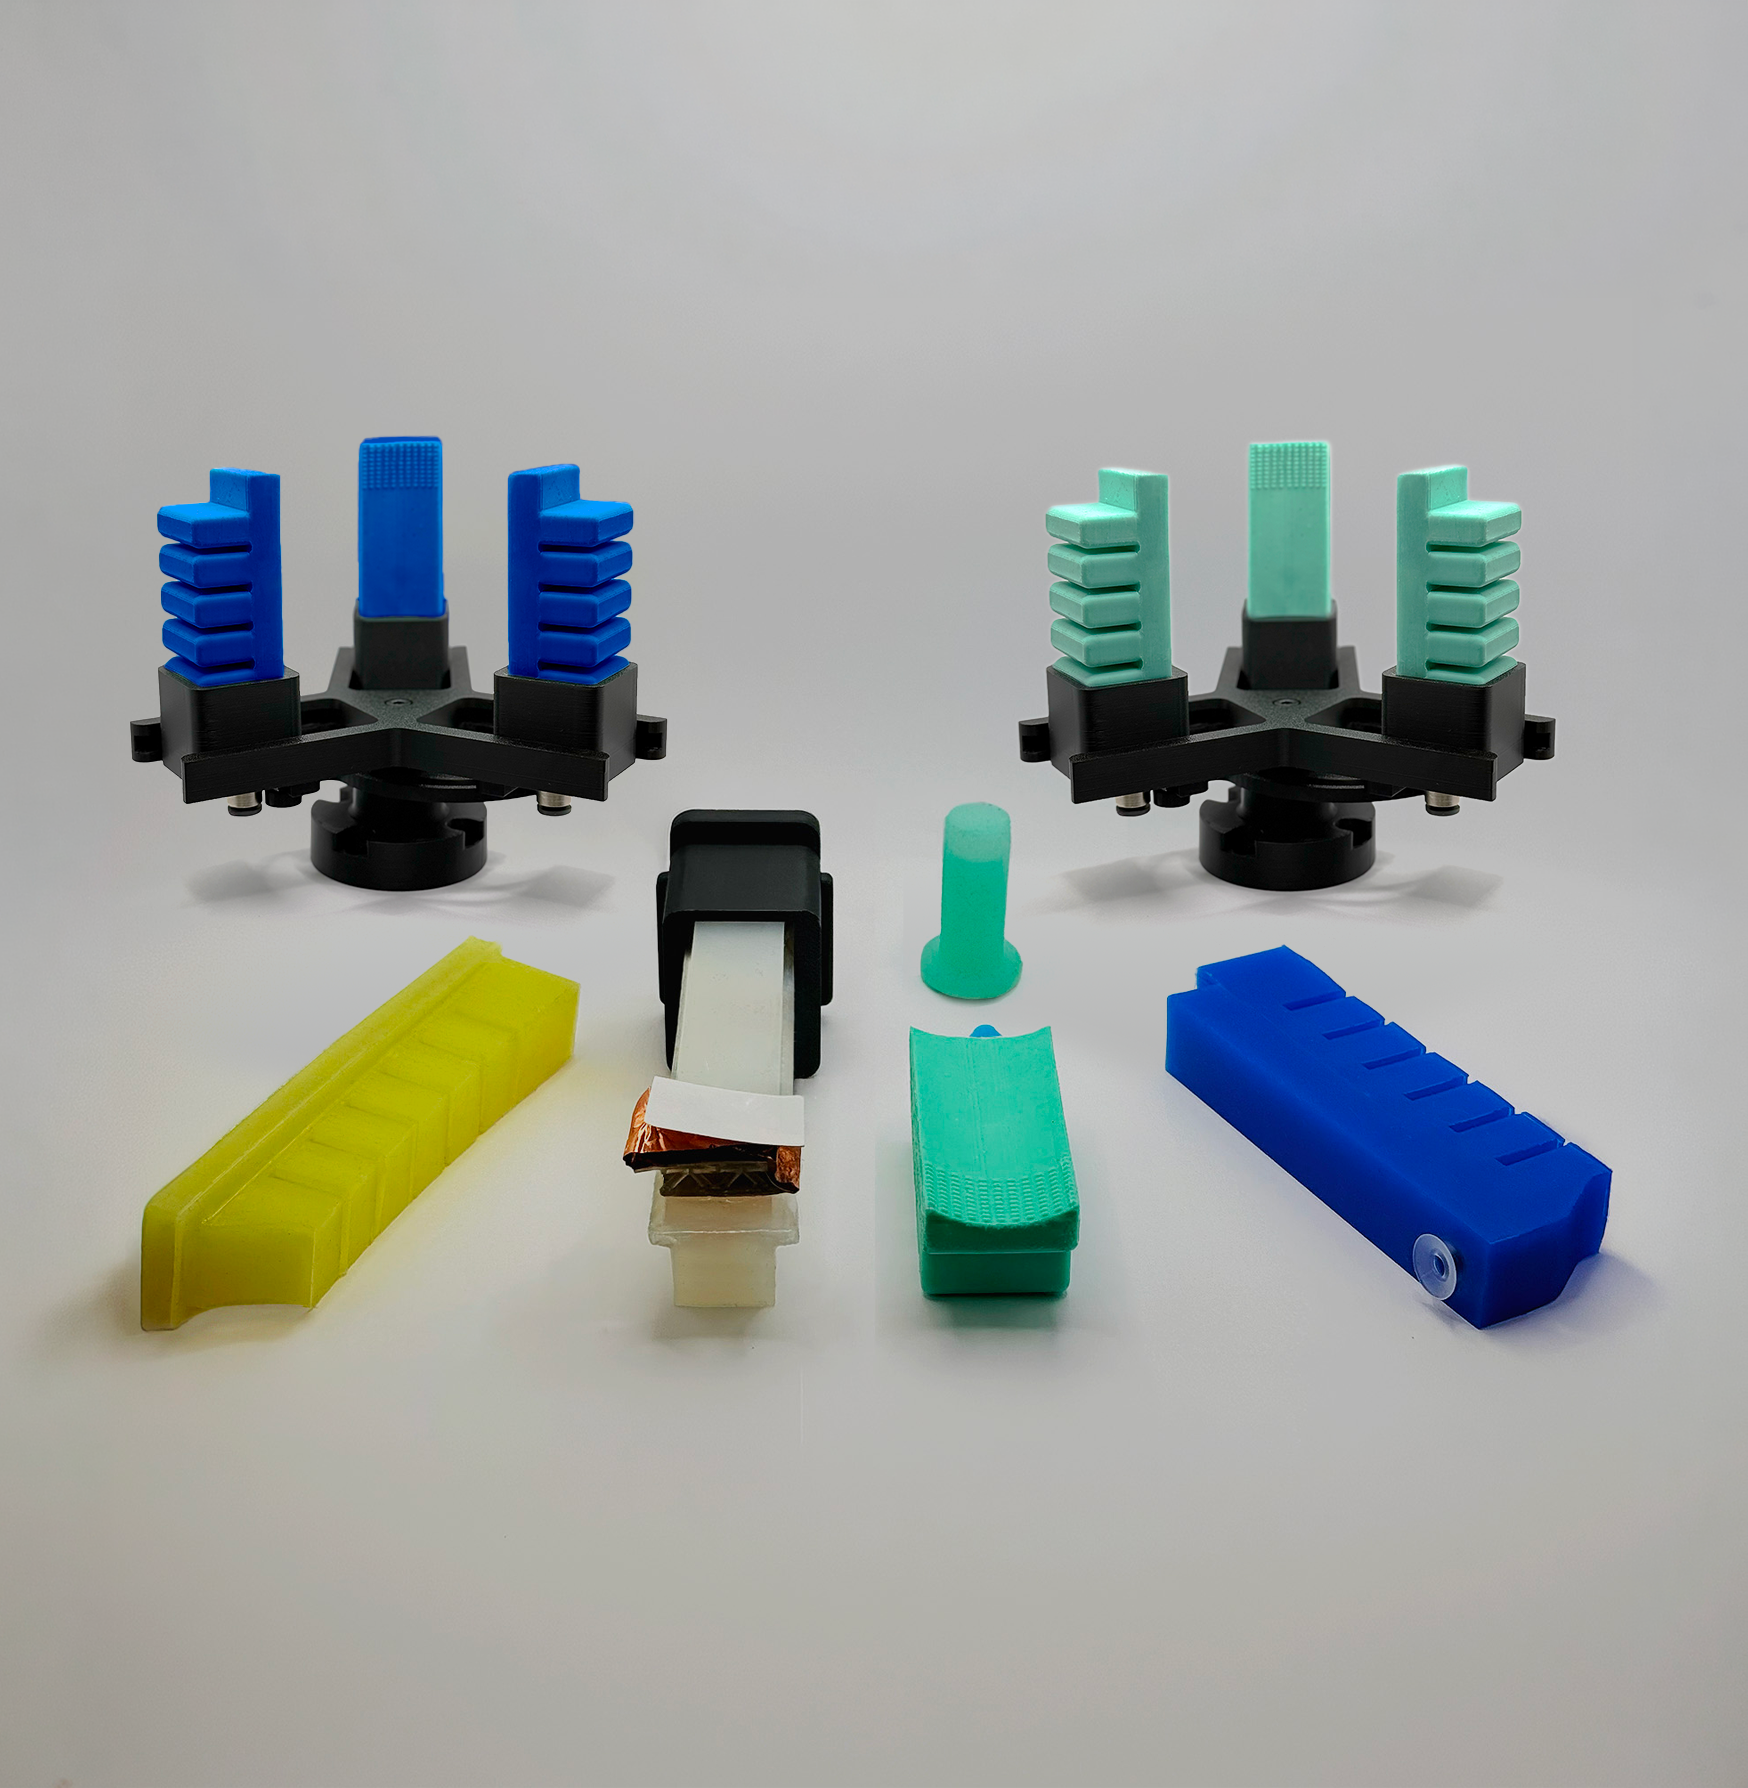
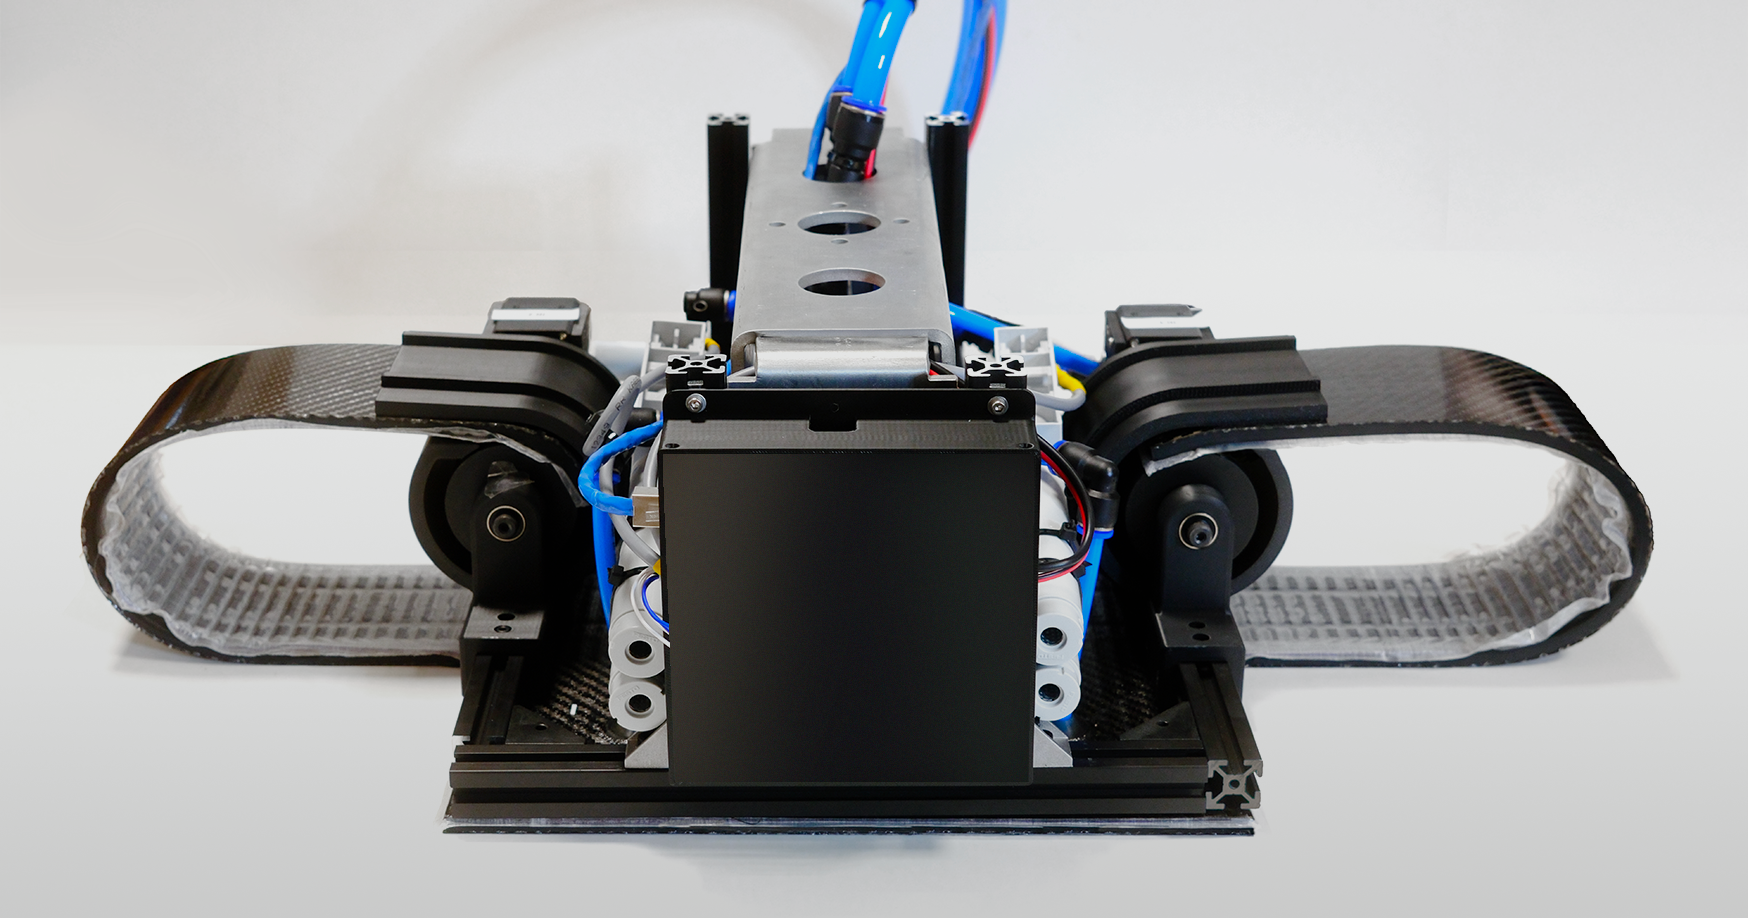
Herobots was responsible for the design and implementation of the soft robotic gripper and its actuation. The device is made of MadFlex composite elements: it starts from a compact, closed configuration and dynamically changes its own geometry, extending to lay onto and conform to surfaces with high geometric variability. Its strength is the selective compliance of the composite, stiff where load has to be transmitted and compliant where it has to follow the leather. Interaction safety is a property of the structure, not a correction applied by the control system. Pressure-sensitive layers integrated into the flexible hardware allow real-time software control of the applied force. The gripper is part of a complete robotic cell for the handling of leather.
Compact
Starts from a closed configuration
Morphing
Dynamically varies its own geometry
Compliant
Safe interaction by design, no marks
Sensorised
Real-time control of applied force
technology
Actuated smart surfaces
Innovative materials, flexible sensing and distributed actuation in a single device.
Morphing technology
Surfaces that change geometry to adapt to the material being handled.
Composite material
MadFlex elements with selective compliance, stiff or flexible where needed.
Sensitive layers
Integrated flexible sensing, distributed across the gripping surface.
Real-time control
Software control over the force applied during gripping.
Distributed actuation
Miniaturised, under-actuated mechanisms distributed across the structure.
PROJECT IN NUMBERS
PARTNERS / FUNDING



Partners
Totaro (system integration and robotic cell) · Test and Manufacturing Engineering, TME (electronics, firmware and sensing) · Composite Research (MadFlex composite material) · Herobots (soft gripper and actuation) · Mario Levi (industrial use case and process requirements).
Programme
MICS, Made in Italy Circolare e Sostenibile, cascade calls.
See all the grippers we have worked on.
They can pick up a large variety of delicate objects and mechanical components, making it ideal for remote assembly/disassembly and maintenance. Integrated with the AI-vision of HeroEye, the Grips enables smart manipulation solutions. Equip it on the HeroArm systems for smart manipulation in constrained environments.
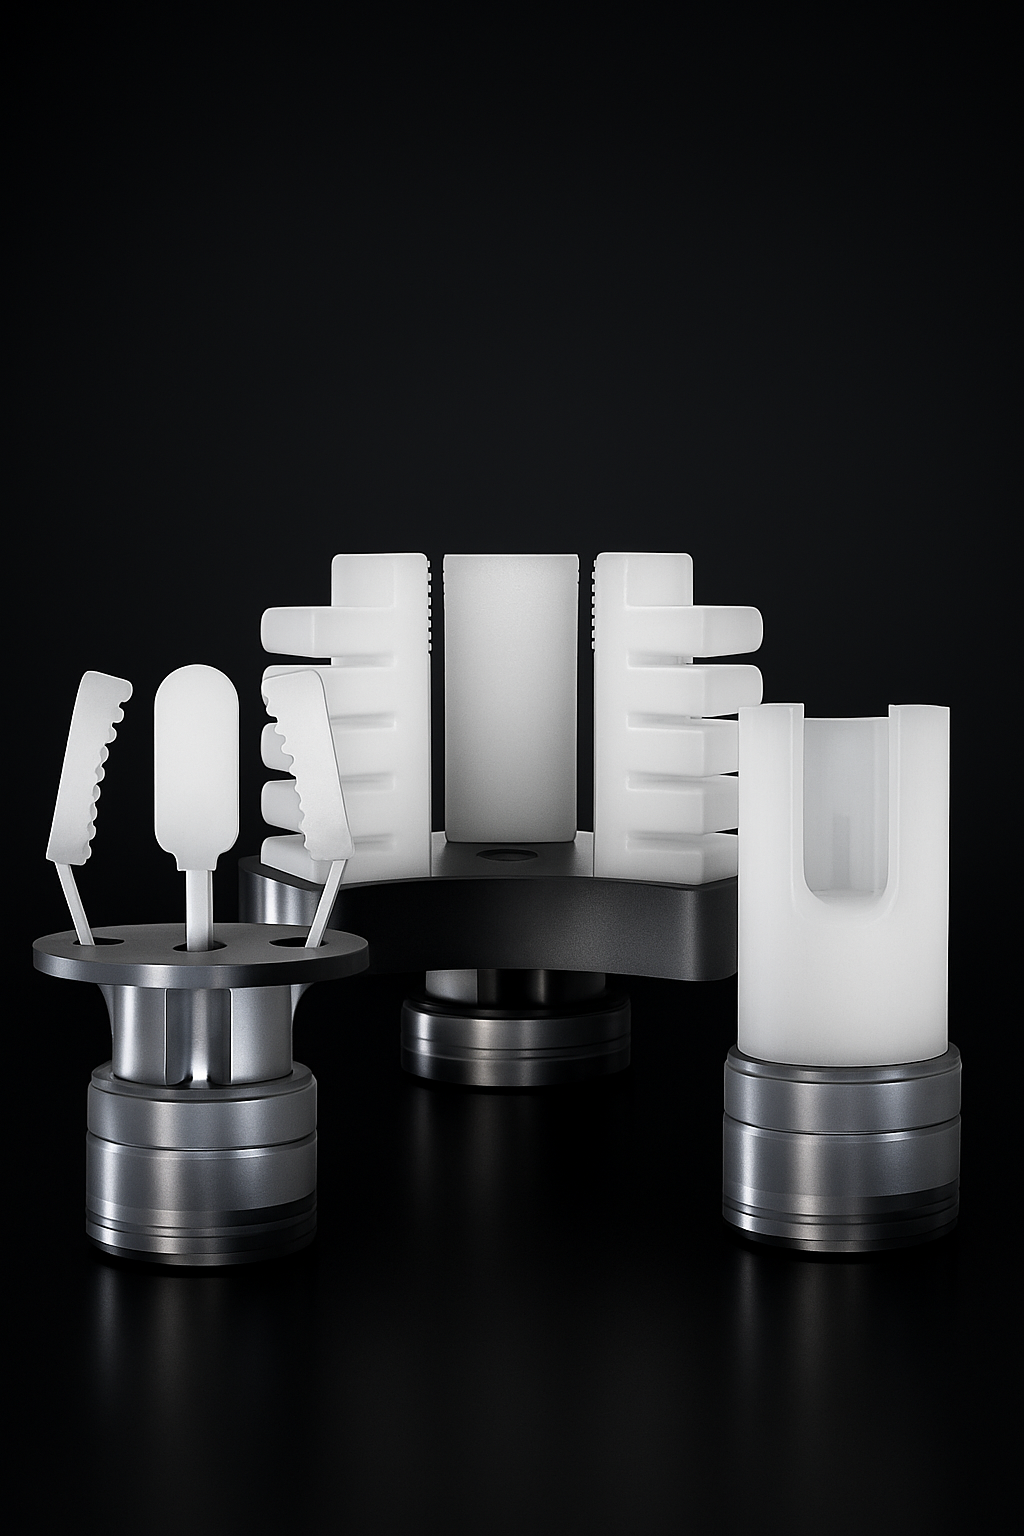
HeroGrip
One grasping platform for multiple objects
Soft and hard materials
Flexible materials for gentle manipulation of delicate objects or hard materials for specific mechanical components
Remote actuation
Remote actuation based on tendon-driven systems or pneumatic solutions based on the object to manipulate.