THE PROJECT
AI-driven robots for sewer inspection and maintenance.
PIPEON is a Horizon Europe project developing robotic solutions that inspect and maintain sewer networks from the inside. Twelve organisations across Europe work on autonomous navigation in harsh environments, defect detection along the network, removal of clogs and blockages, and the installation of sensors in areas nobody can reach. The technologies are tested on three live networks: Heusden, Beerum and Hitra.
Navigate
Autonomous operation in harsh sewer environments
Detect
Defect detection along the network
Remove
Clog and blockage removal
Install
Sensors placed in inaccessible areas
THE CHALLENGE
Sewer networks are running blind.
Large parts of the network are unmapped, so defects go undetected until something fails and the repair becomes an emergency. What monitoring exists is CCTV footage reviewed by hand: slow, expensive and easy to get wrong. The environment itself rules out the obvious answers. Corrosive, abrasive and gas-filled, it keeps people out and wears conventional robots down. Meanwhile clogs of fat, textiles and debris build up until sewage reaches rivers and streets.
HEROBOTS IN THE PROJECT
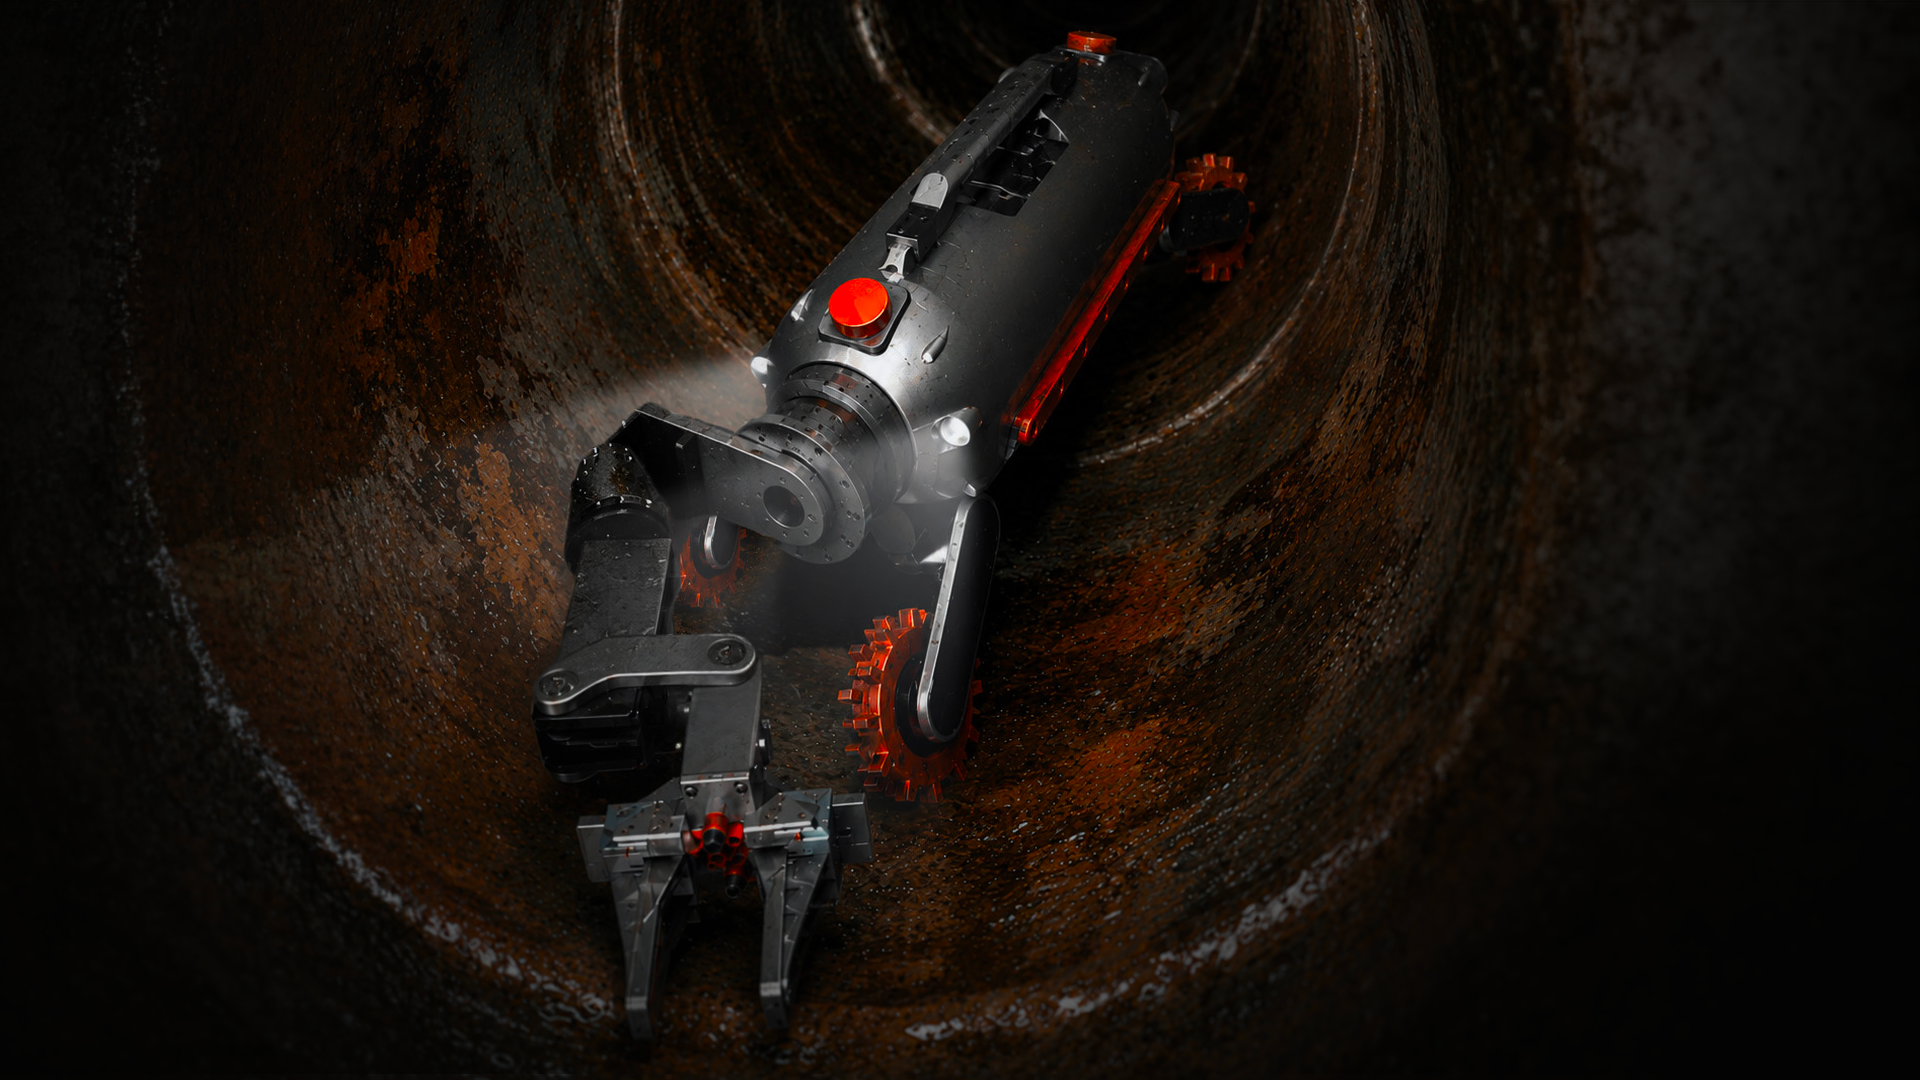
Two robotic arms: Cheliped One and Cheliped Two.
Herobots leads WP3, Manipulation, and develops the two robotic arms that work inside the pipes. Cheliped One is a tendon-driven arm built on T-BOT technology, for inspection and light manipulation in narrow sections. Cheliped Two is a rugged arm built on A-BOT technology, for removing large obstructions. Both are designed to turn and work inside a pipe, in spaces where a person cannot go and a conventional manipulator cannot fit.
Cheliped One
Inspection and light manipulation. Tendon-driven, T-BOT technology.
Cheliped Two
Blockage removal. Rugged, A-BOT technology.
PROJECT IN NUMBERS
PARTNERS / FUNDING


Partners
12 organisations across Europe.
Funding
Horizon Europe, Grant Agreement No. 101189847.
Our role
WP3, Manipulation, led by Herobots.