THE PROJECT
New diagnostics and renewed plants for RFX-mod2.
NEFERTARI renews the plants of RFX-mod2 and equips it with innovative diagnostics. RFX-mod2 is the fusion device of the RFX Consortium in Padova, part of the ESFRI infrastructure and managed together with ISTP Padova. The project strengthens the national network between the CNR laboratories, the University of Padova and the University of Naples Federico II, and contributes to fusion science and technology in Italy in support of DTT, ITER and DEMO. It also includes a new remote maintenance system for the inspection of damaged first-wall components.
THE CHALLENGE
Tiles that have to be replaced from the outside.
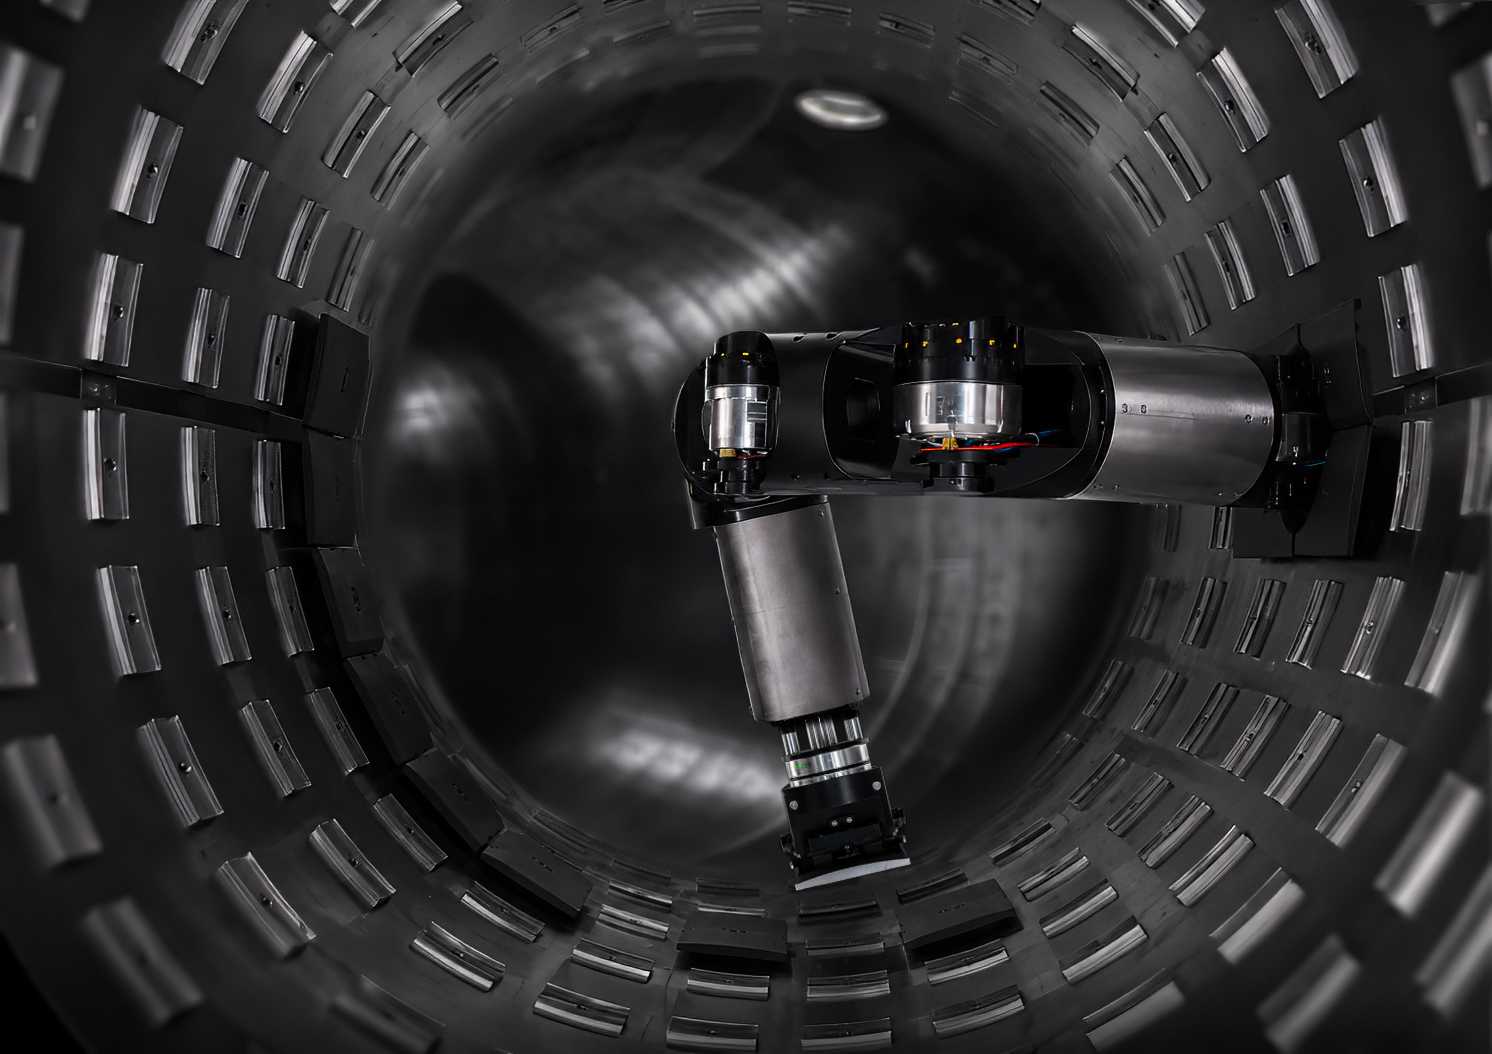
The first wall of RFX-mod2 is made of graphite tiles directly exposed to the plasma. They degrade, and they have to be inspected and replaced inside a toroidal vessel five metres across, with no direct visibility from outside and no room for a person to work. An arm that goes in has to be slim enough to pass through the port, long enough to follow the torus, and strong enough to push a tile into place at the far end of its own reach.
HEROBOTS IN THE PROJECT
We designed and built Roman
with Sophia High Tech.
Roman is the six-degree-of-freedom arm that operates inside the vacuum vessel, delivering more than 200 N of axial force at the end-effector. We designed and built it together with Sophia High Tech, responsible for manufacturing and detailed mechanical design. We also developed TIGER, the tile installation and grasping end-effector, with RGB and depth cameras, a six-axis force and torque sensor and a tip compensator, and the control modules that handle motion, teleoperation and the reconstruction of the internal environment. Herobots contributed to the whole remote handling facility of RFX-mod2, from the manipulator installed on the machine to the 1:1 scale mock-up of a machine sector.
Roman arm
A six-degree-of-freedom manipulator designed to operate inside the toroidal machine.
TIGER gripper
The tile installation end-effector: RGB and depth cameras, a 6-axis F/T sensor and a tip compensator.
Control modules
Control and teleoperation of the arm, with reconstruction of the internal environment.
PROJECT IN NUMBERS
PARTNERS / FUNDING


Partners
CNR (lead), with the ISTP units of Milano, Padova and Bari · Università degli Studi di Padova, Centro Ricerche Fusione · Università degli Studi di Napoli Federico II, DIETI and DII · Sophia High Tech.
Site
Consorzio RFX, Padova, where the RFX-mod2 infrastructure is located.
Funding
PNRR, Avviso n. 3264, Mission 4.